DC linear actuators · Position control from a 4–20 mA, voltage, PWM or CAN command, on a separate board or inside the actuator
Brushed DC linear actuators with a feedback potentiometer cannot hold a commanded position by themselves: something has to compare the setpoint with the wiper voltage and switch the motor. That controller can be a small board between the PLC and the actuator, or electronics built into the actuator housing. The choice turns on the command signal the machine provides, the current the controller must switch, and which protections (stall, temperature, end of stroke) are handled where.
Position and switching controllers for brushed 12, 24 and 48 V DC linear actuators with potentiometer or encoder feedback: stand-alone control boards and onboard actuator electronics, with analogue, PWM, low-level switch and CAN command inputs. Multi-axis motion controllers are covered on the Motion controller page and PC-slot cards on the PCI and PCIe motion control card page; AC servo amplifiers are on the Servo drive page, and servo-motor electric actuators for automation on the Linear actuators (electric, for automation) page.
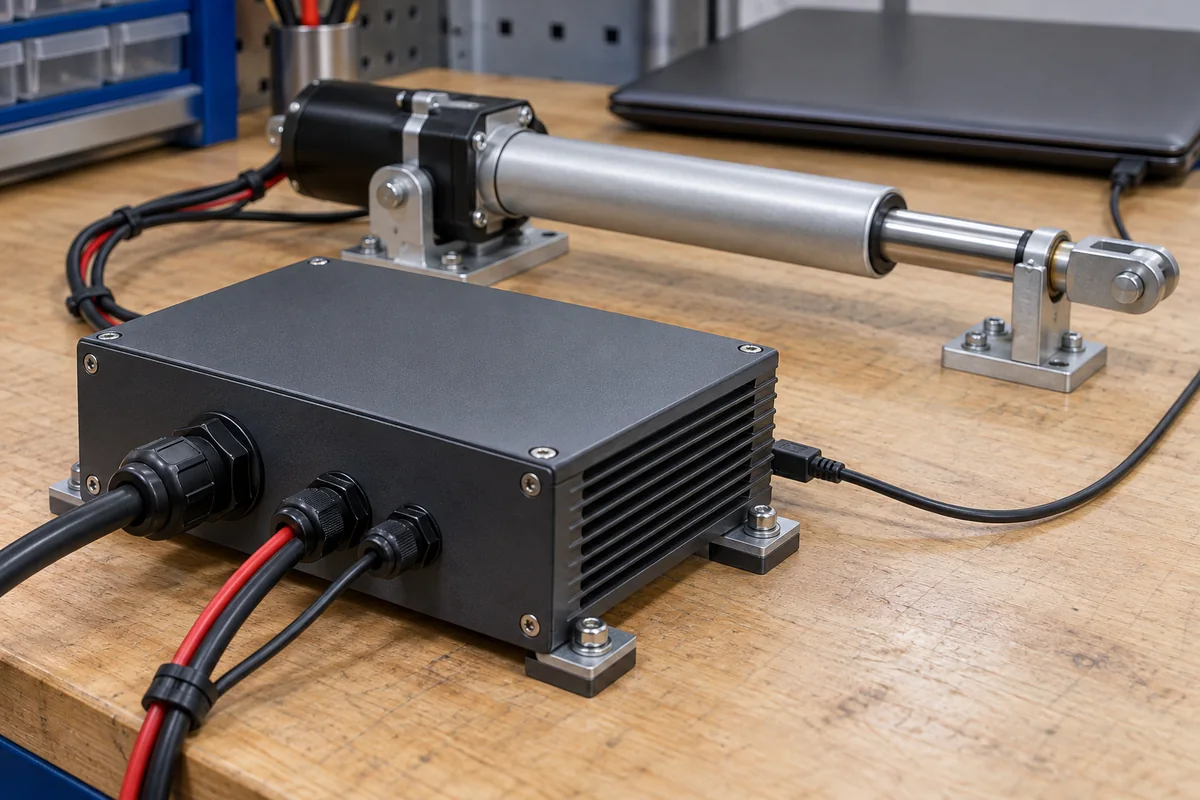
01
Actuonix describes its LAC as a stand-alone closed-loop board that needs as little as one digital or analogue output for position control. At power-up it scans for a valid signal in any of five modes, configures itself to the first one found and disables the others until the next power cycle. [1]
In 4–20 mA mode the LAC takes the setpoint as a current on connector X6 pin 4, held for as long as the position is to be maintained; in PWM mode the duty cycle of a 3.3 V, 1 kHz wave sets the same percentage of full stroke. Its Accuracy trim narrows the dead-band at the risk of jittery motion, and pot settings take effect only after power is cycled. [1] A 4–20 mA loop of this kind belongs to the analogue DC signals for process measurement and control that IEC 60381-1 addresses. [3]
Editorial calculation: for an Electrak HD with 200 mm ordering stroke, signal-follower movement is 200 / 4 = 50 mm per volt, so the 0.5–4.5 V input spans 4 V × 50 mm/V = 200 mm. [2]
Thomson's potentiometer output resolution falls with stroke, from 65.6 Ω/mm at 50–100 mm to 9.8 Ω/mm at 550–1,000 mm, which is worth checking when an external controller reads that pot. [2]
| Feature | Actuonix LAC (separate board) | Thomson Electrak HD (onboard) |
|---|---|---|
| Supply | 6–24 V DC, 4 A peak at 10% duty; must match actuator voltage [1] | HD12 9–16 V, HD24 18–32 V, HD48 36–64 V DC [2] |
| Position command | USB, RC servo pulse (1 ms retract, 2 ms extend), 1 kHz PWM, 0–3.3 V, 4–20 mA [1] | LPS signal-follower 0.5–4.5 V DC; CAN (SAE J1939 or CANopen) [2] |
| Feedback used | Actuator's potentiometer wiper and reference [1] | Wire-wound potentiometer (±0.25% linearity) or hall-effect encoder output options [2] |
| Resolution or repeatability | 10-bit controller [1] | Signal-follower repeatability ±0.1 mm; movement = stroke/4 per volt [2] |
| Limits | Two trim pots set retract and extend limits [1] | Programmable mid-stroke extend and retract limits (LPS) [2] |
| Operating range | −10 to +70 °C, 10–80% RH [1] | Static IP67/IP69K, dynamic IP66 [2] |
02
Thomson's option EXX leaves motor polarity to a customer-supplied switch or relay, which must carry the motor current and an inrush of up to three times the maximum continuous current for up to 150 ms. With LXX the onboard electronics switch the motor, the command switches carry 6–22 mA at 9–32 V, and the supply wiring must still handle inrush of up to one and a half times maximum continuous current for up to 150 ms. [2]
The Electrak monitoring package lists current, voltage and temperature monitoring, load trip point calibration, internal end-of-stroke limit switches and end-of-stroke dynamic braking; braking throughout the stroke is offered only with low-level switching and J1939. Over CAN the actuator accepts position, speed and current commands and returns position, speed, current and diagnostics. The SY2 option synchronises 2 to 8 actuators, with supply voltages within ±10% of each other. [2]
On the board side, Actuonix credits a stall-detection feature with extending actuator life where loads briefly exceed rated force. [1]
03
Paste it into your enquiry below or into an email to a maker, then replace every bracket.
Actuator: [model; voltage; stroke; feedback type] Command: [4–20 mA; 0–10 V or 0.5–4.5 V; PWM; CAN J1939/CANopen] Current: [continuous; inrush] Limits: [hardware or programmable; stall handling] Feedback out: [analogue; digital; end-of-stroke contacts] Environment: [temperature; IP rating]
Manufacturer profiles associated with Actuator Controller.
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Yes, through a controller: Actuonix's LAC accepts a 4–20 mA setpoint and drives a potentiometer-feedback actuator to the matching position. [1]
Thomson specifies up to three times maximum continuous current for 150 ms when an external switch reverses the motor, and up to 1.5 times with its onboard switching. [2]
Thomson lists ±0.1 mm repeatability for the Electrak HD signal-follower with a 0.5–4.5 V input. [2]
Sources checked 2026-10-17. Actuonix's LAC datasheet describes a separate control board; Thomson's Electrak HD catalogue (dealer-hosted copy) the onboard alternative. The IEC 60381-1 scope comes from the EVS catalogue.
Ask for use case, specification boundaries, supplier type, and RFQ preparation information for this product.
Compare manufacturer profiles with relevant product and process capability.