MEMS gyroscopes (angular rate sensors) · Range and sensitivity, zero-rate offset and its drift, noise and bandwidth, shock rating, supply and interface
A gyroscopic sensor measures angular rate — how fast something rotates — and, integrated over time, the change in angle; MEMS gyroscopes do this on a chip for stabilisation, navigation and motion control. Settle three things before choosing one: the measurement range and bandwidth the motion needs, the offset, offset drift and noise that decide how quickly the computed angle wanders, and the supply, interface, package and shock environment.
MEMS angular rate sensors (gyroscopes) as chips and modules. Complete inertial measurement units sold with fusion firmware, inclinometers, fibre-optic and ring-laser gyroscopes and mechanical gyroscopes are outside this page; inertial measurement units have their own page.
CNFX editorial research · Sources checked October 12, 2026 · 4 sources
Bosch Sensortec's BMI088 datasheet describes a triaxial 16-bit gyroscope packaged with a triaxial accelerometer in a 3.0 × 4.5 × 0.95 mm LGA, with SPI or I²C interfaces. The gyroscope range is selectable at ±125, 250, 500, 1,000 or 2,000 °/s, with sensitivity from 262.144 LSB per °/s at ±125 °/s to 16.384 LSB per °/s at ±2,000 °/s, sensitivity tolerance of ±1%, sensitivity change over temperature of ±0.03 %/K, nonlinearity of ±0.05 %FS, cross-axis sensitivity of ±1% and g-sensitivity of 0.1 °/s/g. [1]
The datasheet lists output data rates of 100 to 2,000 Hz and −3 dB bandwidths of 12 to 523 Hz depending on the filter setting. [1]
Bosch Sensortec's BMI270 and BMI323 six-axis IMUs offer the same gyroscope ranges of ±125 to ±2,000 °/s with 16-bit output and sensitivity from 262.144 to 16.384 LSB per °/s. The BMI270 lists gyroscope output data rates of 25–6,400 Hz in normal and performance modes (25–100 Hz in low-power mode) and 0.01% FS nonlinearity; the BMI323 lists 12.5–6,400 Hz (down to 0.78 Hz in low-power mode) with −3 dB bandwidths from 6.2 Hz to 563 Hz depending on the setting. [2][3]
Editorial calculation: at the ±2,000 °/s range one LSB is about 0.061 °/s; at ±125 °/s it is about 0.0038 °/s. Choose the smallest range that still covers the fastest expected rotation, so that resolution is not wasted. [1]
A second maker shows the range can extend lower: TDK InvenSense lists user-selectable gyroscope full-scale ranges of ±15.6, 31.2, 62.5, 125, 250, 500, 1,000 and 2,000 dps for its ICM-42688-P six-axis device, in a 0.91 × 2.50 × 3.00 mm package with a 12.5 MHz I3C, 1 MHz I²C or 24 MHz SPI host interface and a 19-bit gyroscope data format in its FIFO. [4] A narrow range suits slow motion such as platform levelling; a wide range is for fast rotation where saturation would lose the angle.
Give the supplier the measurement range per axis, bandwidth and output data rate, required zero-rate offset and offset drift, noise density, sensitivity tolerance and nonlinearity, g-sensitivity limit, supply voltage and current, interface (SPI, I²C, analog, CAN), package or module size, operating temperature, shock and vibration environment, qualification grade and quantity.
02
Check zero-rate offset, drift, noise and environment
The BMI088 datasheet lists zero-rate offset of ±1 °/s at 25 °C with offset cancellation off, offset change over temperature of ±0.015 °/s per K from −40 to +85 °C, supply-voltage drift below 0.1 °/s per V, and output noise of 0.1 °/s rms in a 47 Hz bandwidth, which it states as 0.014 °/s/√Hz. [1]
It lists 5 mA gyroscope supply current in normal mode at 1 kHz output, 25 µA in suspend, 30 ms start-up to within ±1 °/s, supply of 2.4–3.6 V (I/O 1.2–3.6 V), operation from −40 to +85 °C, and absolute maximum mechanical shock of 10,000 g for 200 µs or 2,000 g for 1 ms, with 2 kV HBM ESD. [1]
The BMI270 lists zero-rate offset of ±0.5 °/s over life at 25 °C, offset change of ±0.015 °/s per K, sensitivity error of ±2% over life (±0.4% after its component retrimming), and output noise of 0.007 °/s/√Hz in performance mode and 0.010 °/s/√Hz in normal mode, or 0.07 and 0.09 °/s rms in a 74.6 Hz bandwidth. The BMI323 lists ±1 °/s zero-rate offset over life, ±0.04 °/s per K offset change, ±0.7% sensitivity error after self-calibration (±3% without), 0.007 °/s/√Hz noise density in high-performance mode, and an offset shift of ±1.1 °/s per millistrain of PCB bending. [2][3]
Editorial calculation: 0.007 °/s/√Hz over the BMI270's 74.6 Hz bandwidth gives about 0.060 °/s rms (0.007 × √74.6), close to its listed 0.07 °/s rms. The BMI323's PCB-strain figure means board bending during assembly or mounting can shift offset as much as its temperature drift over about 28 K (1.1 ÷ 0.04 ≈ 28 K). [2][3]
Editorial calculation: a 40 K temperature swing at ±0.015 °/s per K shifts the offset by up to 0.6 °/s; integrated for 60 s without correction that is 36° of heading error. Noise of 0.014 °/s/√Hz equals an angle random walk of about 0.84 °/√h (× 60). Offset drift, not noise, then dominates over minutes, so plan temperature compensation or an external heading reference. [1]
TDK InvenSense lists gyroscope noise of 2.8 mdps/√Hz for the ICM-42688-P and a six-axis current of 0.88 mA in low-noise mode. [4] Editorial calculation: 2.8 mdps/√Hz is 0.0028 °/s/√Hz, one fifth of the BMI088's 0.014 °/s/√Hz, and corresponds to an angle random walk of about 0.17 °/√h (0.0028 × 60). Compare noise figures in the same unit before comparing parts. [4][1]
03
Find suppliers
The companies in the manufacturer list below show this product on their own websites. Confirm the legal seller, factory and scope for your order.
Ask any supplier for the full datasheet with offset, offset drift, noise density and bandwidth at your range, and for the shock and qualification data. [1]
04
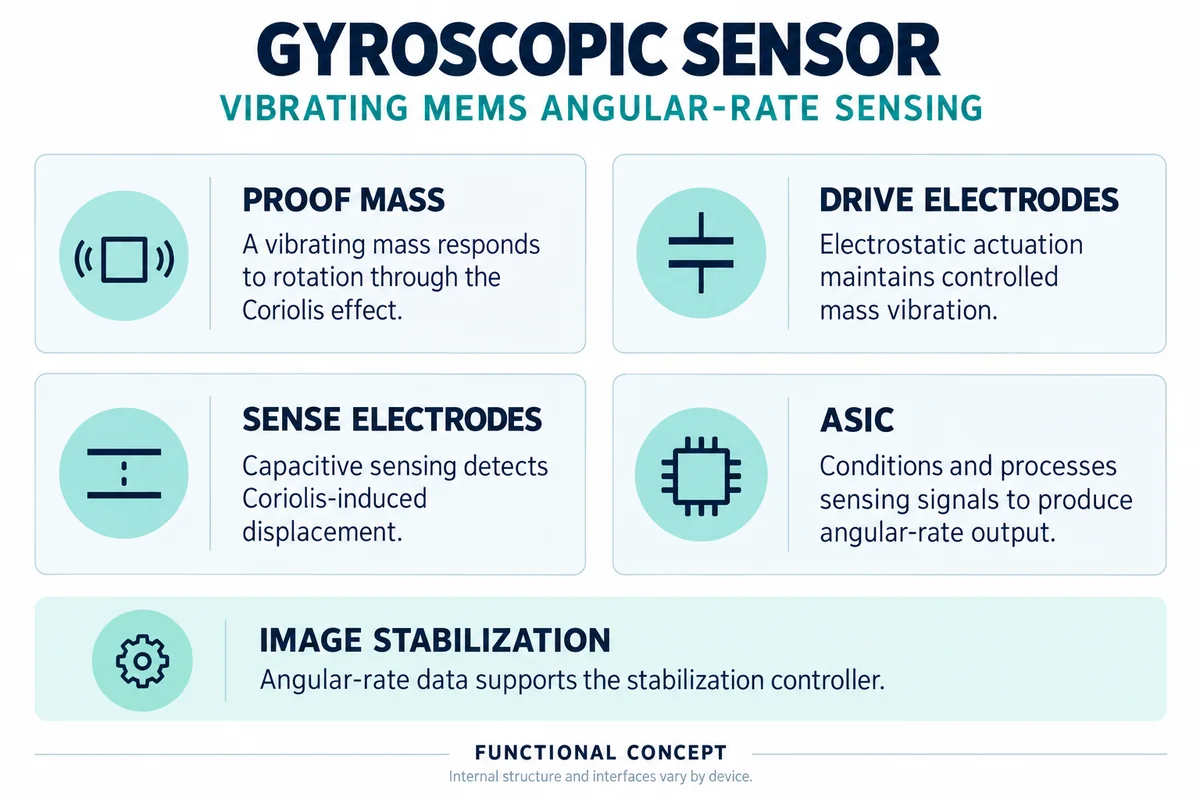
Trace what each block controls
This is a functional reference built from the sources cited; it is not one maker's specification.
Fill the specification fields with values for your motion
A gyroscope quotation needs values for your motion. The table explains each field, gives published values where a reviewed source states them, and says what to obtain from the supplier.
Field
What it means and published values
Ask the supplier for
Measurement Range
±125 to ±2,000 °/s selectable. [1] ±15.6 to ±2,000 dps on another part. [4]
Range.
Bias Stability
Offset ±1 °/s; drift ±0.015 °/s/K. [1] Offset drift ±0.015–0.04 °/s per K in other parts. [2][3]
In-run bias stability.
Angular Random Walk
0.014 °/s/√Hz noise density. [1] Noise density 0.007 °/s/√Hz in high-performance modes. [2][3] 2.8 mdps/√Hz on another part. [4]
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Share this page
Compiled and source-reviewed by the CNFX editorial team.
Published datasheets show stated performance, not tested results. Confirm the legal seller, maker and datasheet for your order. How we source and review
· Page last updated 13 October 2026
Buyer questions
What range does a MEMS gyroscope cover?
Bosch's BMI088 gyroscope is selectable from ±125 to ±2,000 °/s. [1]
What is zero-rate offset?
The output with no rotation; the BMI088 lists ±1 °/s at 25 °C and ±0.015 °/s per K change over temperature. [1]
How noisy is a MEMS gyroscope?
The BMI088 lists 0.014 °/s/√Hz, or 0.1 °/s rms in 47 Hz. [1]
How much shock can a MEMS gyroscope survive?
The BMI088 lists 10,000 g for 200 µs as an absolute maximum. [1]
Does board mounting affect a MEMS gyroscope?
Yes; one datasheet lists a zero-rate offset shift of ±1.1 °/s per millistrain of PCB bending, so mounting stress matters as much as temperature. [3]
Sources and what still needs a direct check
Sources checked 2026-10-12. Bosch Sensortec publishes the BMI088, BMI270 and BMI323 datasheets with full gyroscope specifications; TDK InvenSense's ICM-42688-P product page gives a second maker's range, noise and current figures.