CAN Protocol Engine
View system integration details
This page explains how Error Management Logic is classified within Motor Vehicle Manufacturing. Technical values and manufacturer relationships are research references; confirm the current specification and supplier evidence for each order.
A subsystem within the CAN Protocol Engine responsible for detecting, classifying, and responding to communication errors on the CAN bus.
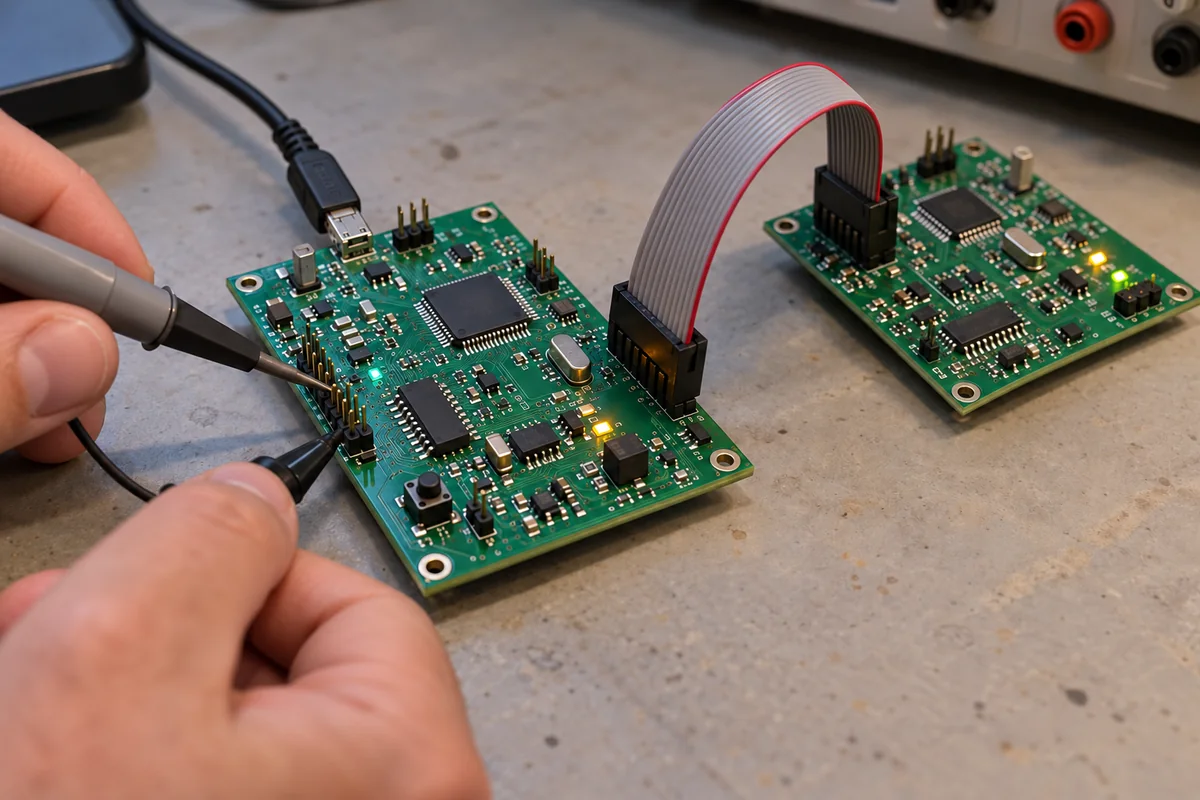
Technical details and manufacturing context for Error Management Logic
| Parameter | Typical range | Notes & selection driver |
|---|---|---|
| Operating Voltage | 9–36 V DC | Outside this range the transceiver may fail.ISO 11898-2 |
| Operating Temperature | -40–85 °C | Exceeding limits may cause erratic behavior.ISO 16750-4 |
| Error Passive Threshold | 128 count | Above this count the node becomes error passive.ISO 11898-1 |
| Bus Off Recovery Time | 128–256 bit times | Determines re-integration after bus-off.ISO 11898-1 |
| Error Counter Increment | 1–8 count | Depends on error type.ISO 11898-1 |
| Error Counter Decrement | 1 count | Decrement per successful reception.ISO 11898-1 |
| TEC Limit for Bus Off | 255 count | Exceeding this triggers bus-off state.ISO 11898-1 |
| TEC Limit for Error Passive | 127 count | Above this the node becomes error passive.ISO 11898-1 |
| REC Limit for Error Passive | 127 count | Above this the node becomes error passive.ISO 11898-1 |
| Error Interrupt Latency | 1–10 µs | Time from error detection to interrupt. |
| Error Status Register Width | 8 bit | Number of bits for error flags. |
| Power Consumption | 5–50 mA | At 3.3V supply, typical. |
Ranges are indicative industry figures for RFQ preparation, not a supplier commitment. Confirm every value and standard with the legal manufacturer before ordering.
| pressure: | N/A (electronic subsystem) |
| other spec: | CAN bus voltage: 3.3V or 5V, Error detection latency: <1ms |
| temperature: | -40°C to +125°C |
Indicative industry ranges for design and RFQ preparation. Confirm the exact figures and applicable standard with the manufacturer before specifying.
Quoted from the published standard.
A practical evidence checklist for RFQ preparation and supplier evaluation.
Compare the published product scope and source details, then include your specifications and quantity in an enquiry.
Manufacturer profiles associated with Error Management Logic.
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Ask for use case, specification boundaries, supplier type, and RFQ preparation information for this product.
It monitors the CAN bus for communication errors, classifies them, and manages the node's error state and recovery actions to maintain network reliability.
It detects bit errors, stuff errors, CRC errors, form errors, and acknowledgment errors as defined by the CAN protocol.
It changes the node's error state (Error Active, Error Passive, Bus Off) based on error counter thresholds, which determines whether the node can transmit error flags or must recover.
Operating voltage (9-36 V DC), temperature range (-40 to 85 °C), error passive thresholds, bus-off recovery time, and error counter increments. Always confirm with the manufacturer for your specific model.
This component is essential for the following industrial systems and equipment:
Commonly used trade names and technical identifiers for Error Management Logic.
Editorial classification, named public sources where available, and source-reviewed manufacturer records.
Compare manufacturer profiles with relevant product and process capability.