Editorial Technical Reference

Robotic Transfer Arm

This page explains how Robotic Transfer Arm is classified within Machinery and Equipment Manufacturing. Technical values and manufacturer relationships are research references; confirm the current specification and supplier evidence for each order.

Technical Definition & Core Assembly

A robotic arm component designed for automated material transfer within handling systems.
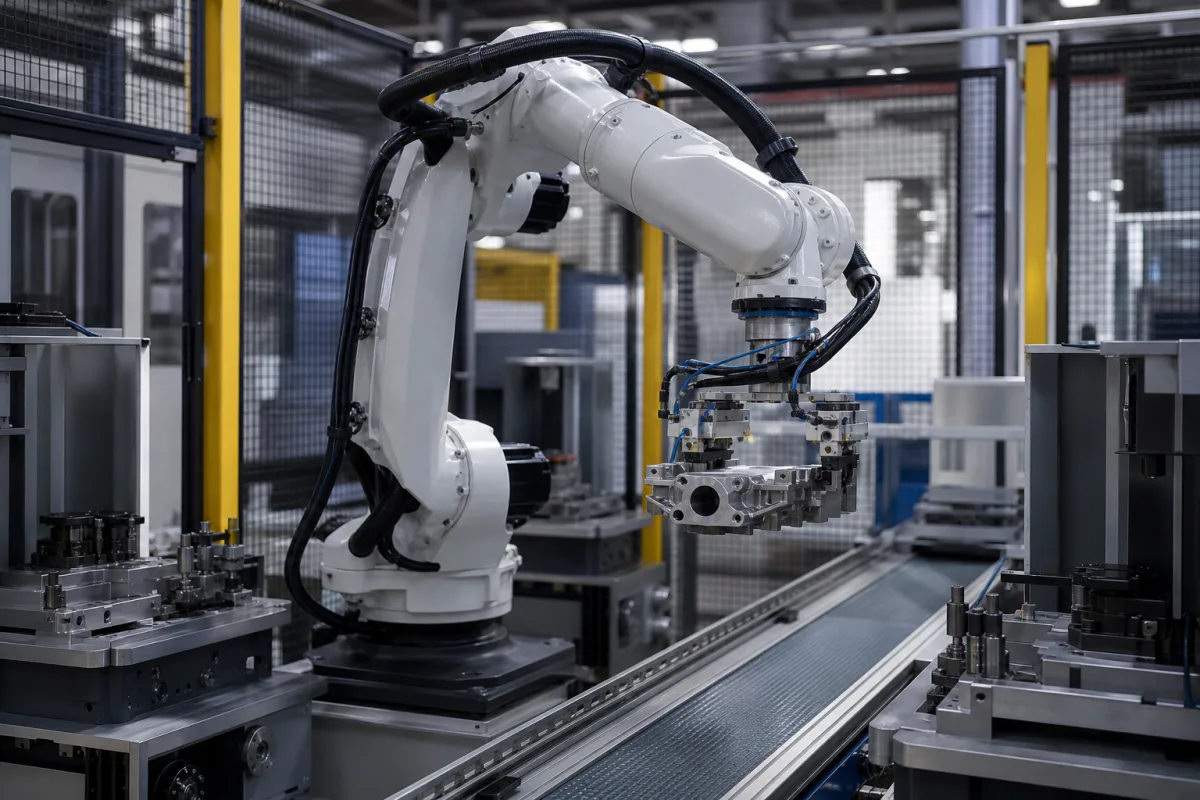
Robotic Transfer Arm in a manufacturing environment
Representative product image. Confirm appearance and specifications with the manufacturer.

Product Specifications

Technical details and manufacturing context for Robotic Transfer Arm

Definition
The Robotic Transfer Arm is a specialized component used in Automated Material Handling Systems (AMHS). It is responsible for precisely picking up, moving, and placing materials, components, or products between different stations, conveyors, or processing units within a manufacturing or logistics environment. This arm is typically mounted on a fixed base and features multiple articulated joints that allow for multi-axis motion, enabling it to reach various positions within its workspace.

The arm operates under programmed instructions from a central controller. Actuators—which may be electric, pneumatic, or hydraulic—drive the joints, providing the necessary force and precision. An end-effector, such as a gripper or suction cup, interfaces with the load to securely handle items. Sensors provide feedback on position, force, and object presence, ensuring accurate and reliable transfer operations.

Key specifications include a rated load capacity of 5–50 kg (at full speed; higher loads reduce speed), a reach of 800–2000 mm from the base to the wrist flange, and 4–6 degrees of freedom. Repeatability is ±0.05–±0.1 mm at rated load, and maximum speed ranges from 1–3 m/s. The arm operates in ambient temperatures from -10°C to 50°C and has an IP54–IP65 protection class. It requires a 24 V DC ±10% power supply and consumes 0.5–2.5 kW on average. The arm itself weighs 50–300 kg (without controller or end-effector). Mounting options include floor, wall, or ceiling. Housing and structural components are typically made of aluminum or steel, with composite polymers also used in some parts.

This product is intended as a component for integration into larger systems. All values are reference ranges and must be verified for the specific model and application with the legal manufacturer or supplier.
Working Principle
The Robotic Transfer Arm operates through programmed instructions from a central controller. The controller sends commands to actuators—typically electric, pneumatic, or hydraulic—which drive the arm's articulated joints, enabling precise multi-axis motion. An end-effector, such as a gripper or suction cup, interfaces with the load to pick up, move, and place items. Sensors provide real-time feedback on position, force, and object presence, allowing the controller to adjust movements for accurate and reliable transfer operations. The arm's degrees of freedom (4–6) determine its flexibility in reaching various positions. The system is designed for integration into larger automated material handling systems, with the arm acting as a key component.
Common Materials
Aluminum alloy, Steel, Composite polymers
Technical Parameters
ParameterTypical rangeNotes & selection driver
Rated Load Capacity5–50 kgMaximum payload at full speed; higher loads reduce speed.ISO 9283
Reach800–2000 mmHorizontal distance from base to wrist flange.
Degrees of Freedom4–6Number of independent axes for positioning.
Repeatability±0.05–±0.1 mmPositioning precision at rated load.ISO 9283
Maximum Speed1–3 m/sLinear speed of end effector at full extension.
Operating Temperature-10–50 °CAmbient temperature range for continuous operation.
Protection ClassIP54–IP65Dust and water resistance for industrial environments.IEC 60529
Power Supply24 ±10% V DCStandard industrial DC voltage.
Power Consumption0.5–2.5 kWAverage power draw during operation.
Weight50–300 kgArm mass without controller or end effector.
Mounting TypeFloor, wall, ceilingOrientation flexibility for layout optimization.
MaterialAluminum, steelHousing and structural components.

Ranges are indicative industry figures for RFQ preparation, not a supplier commitment. Confirm every value and standard with the legal manufacturer before ordering.

Components / BOM
  • Arm Structure/Links Part
    Provides the rigid framework and determines the arm's reach and kinematics
    Material: Aluminum alloy or steel
  • Joints/Actuators
    Enable rotational or linear movement at each axis, typically driven by servo motors
    Material: Steel, copper windings, magnets
  • End-Effector Interface Part
    Mounting point for attaching grippers, suction cups, or other tooling to interact with the load
    Material: Steel
  • Wiring Harness & Connectors
    Transmits power and control signals to actuators and sensors throughout the arm
    Material: Copper, insulating polymers
  • Feedback Sensors
    Report joint position, grip force and whether a part is actually there.

Applied To / Applications

This component is essential for the following industrial systems and equipment:

Industrial Ecosystem & Supply Chain Structure

Complementary Systems
Downstream Applications
Specialized Tooling

Application Fit & Sizing Matrix

Operational Limits
pressure: 0 to 10 bar
temperature: -20°C to 80°C
repeatability: ±0.1 mm
operating speed: 0.1 to 2.0 m/s
payload capacity: 1 to 50 kg
Media Compatibility
✓ plastic pellets ✓ metal components ✓ packaged goods
Unsuitable: highly corrosive chemical baths
Sizing Data Required
  • maximum payload weight
  • required reach/working envelope
  • cycle time requirements

Reliability & Engineering Risk Analysis

Failure Mode & Root Cause
Bearing fatigue and wear
Cause: Cyclic loading from repetitive arm movements leads to material fatigue, compounded by inadequate lubrication or contamination ingress, causing premature bearing failure and positional inaccuracy.
Motor drive system overheating
Cause: Excessive duty cycles or mechanical binding increase current draw, generating heat that degrades insulation and windings, often due to poor ventilation, misalignment, or controller faults.
Maintenance Indicators
  • Unusual grinding or clicking noises during movement, indicating bearing or gear wear
  • Erratic or jerky motion with position drift, signaling drive or feedback system degradation
Engineering Tips
  • Implement predictive maintenance using vibration analysis and thermal imaging to detect early bearing and motor issues before catastrophic failure.
  • Establish strict contamination control and lubrication schedules with high-quality greases, and ensure proper alignment during installation to reduce mechanical stress.

Indicative industry ranges for design and RFQ preparation. Confirm the exact figures and applicable standard with the manufacturer before specifying.

Compliance & Manufacturing Standards

Applicable Standards
ISO 10218-1:2011 - Robots and robotic devices - Safety requirements for industrial robots ANSI/RIA R15.06 - Industrial Robots and Robot Systems - Safety Requirements CE Marking - Directive 2006/42/EC on machinery safety

Quoted from the published standard.

Manufacturing Precision
  • Positional repeatability: +/-0.05mm
  • End-effector alignment: +/-0.1° angular deviation
Quality Inspection
  • Laser interferometer calibration for positional accuracy
  • Load cycle fatigue testing with simulated operational conditions

Manufacturers of Robotic Transfer Arm

Manufacturer profiles associated with Robotic Transfer Arm.

Sourcing Robotic Transfer Arm from China?
Tell us your specification and target quantity — we will match it against manufacturer records and come back with the factories that fit.
Request manufacturers We manufacture this

Manufacturer listings support early research and capability understanding. They are not certification, ranking, or transaction guarantees.

Share this page
Technical documentation
Request current drawings, revision history, and a signed specification sheet.
Manufacturing capability
Verify equipment lists, process limits, capacity, and representative production evidence.
Inspection readiness
Confirm test methods, calibrated equipment, sampling plans, and traceable reports.
Supplier transparency
Check the legal entity, factory address, ownership, certifications, and direct contacts.

CNFX does not score or rank suppliers. Buyers must verify all claims and documents with the legal manufacturer before ordering.

Supply Chain Compatible Machinery & Devices

Automated Powder Coating System

Integrated industrial system for applying dry powder coatings to metal substrates.

Explore Specs →
Centrifugal Pump Impeller

The centrifugal pump impeller is a critical rotating component that converts mechanical energy from the motor into kinetic energy in fluid systems.

Explore Specs →
High-Precision CNC Laser Cutting Machine

Computer-controlled industrial machine using focused laser beams to cut sheet metal with micron-level accuracy.

Explore Specs →
Industrial-Grade Hydraulic Cylinder Piston Rod

This industrial-grade piston rod is a precision-ground cylindrical component designed for use in hydraulic cylinders.

Explore Specs →

Frequently Asked Questions

What is the rated load capacity of the Robotic Transfer Arm?

The rated load capacity is 5–50 kg at full speed. Higher loads may reduce the operating speed. This is a reference range; the exact capacity for a specific model must be confirmed with the manufacturer.

What are the mounting options for this arm?

The arm can be mounted on the floor, wall, or ceiling, providing flexibility for layout optimization. The choice of mounting affects the reach and workspace, so it should be selected based on the application requirements.

What is the repeatability of the arm?

Repeatability is ±0.05 to ±0.1 mm at rated load, as per ISO 9283. This indicates the precision with which the arm can return to a programmed position. Actual repeatability may vary with load and speed.

What power supply does the arm require?

The arm requires a 24 V DC ±10% power supply. The average power consumption during operation is 0.5–2.5 kW. Ensure the power supply meets these specifications for reliable operation.

Data Basis

Editorial classification, named public sources where available, and source-reviewed manufacturer records.

Preliminary Technical Classification
This page supports structured research, RFQ preparation, and supplier evaluation. It does not replace buyer-led supplier qualification, standards review, or technical approval.
Buyer enquiry

Request manufacturing insight for Robotic Transfer Arm

Ask for use case, specification boundaries, supplier type, and RFQ preparation information for this product.

Where it goes
Straight to the CNFX editorial desk, and to the manufacturer if this product is linked to a claimed profile. Nothing is broadcast to a supplier list.
Your details stay here
We do not sell or rent enquiry data, and we do not add you to a mailing list. Used only to answer this request.
No commission, no middleman
CNFX is a directory. We take no cut of any order and never negotiate on a supplier's behalf.
What we don't claim
A listing is not an endorsement. Qualify every supplier and verify every figure yourself before ordering.

Your business information is used only to process this request.

Thank you! Your message has been sent. We'll respond within 1–3 business days.
Sorry, we couldn't send your message. Please try again, or email us at [email protected].

Need to Manufacture Robotic Transfer Arm?

Compare manufacturer profiles with relevant product and process capability.

Previous Product
Z-axis Ram/Spindle
Last Product
Get QuotesChat