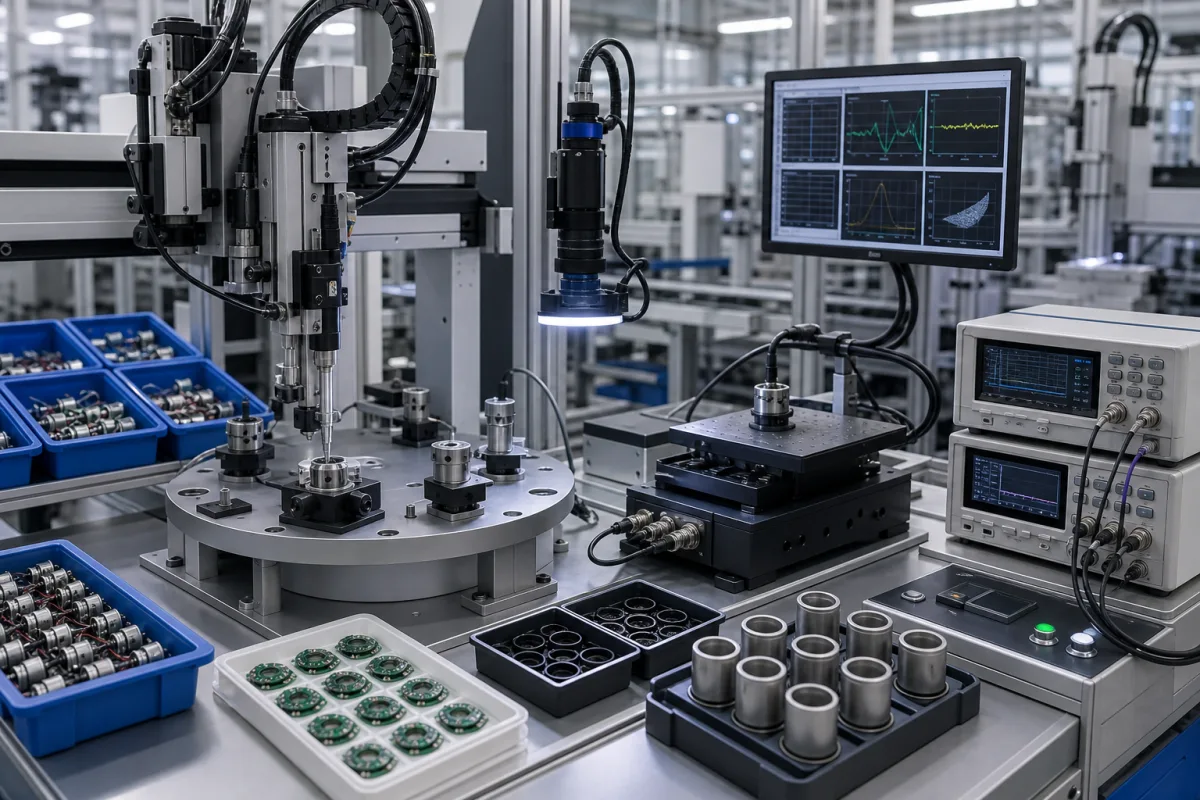
Vibration motor module assembly and test cell for personal massagers: rotary dial stations and 100 g jig acceptance test
Motor-module cell for vibrating personal massagers · rotary dial with nests, motor pressing and joining, then a 100 g jig test of G, speed, current and noise
In a vibrating personal massager the part that decides whether the product works is the motor module: a coin or cylindrical eccentric-mass motor, or a linear resonant actuator, fixed in a holder and wired to a small board. A cell that builds these modules can be laid out as a rotary dial carrying nests past a few stations, with a test position at the end where each module is driven and its vibration measured. Two things need defining before a cell is quoted: how precisely the dial places each nest under the pressing and joining tools, and what test the last station runs, on what jig, against which limits.
Assembly and test cells for the vibration motor module of personal massagers and similar handheld vibrating devices: rotary indexing dials with part nests, motor pressing and joining stations, camera checks, and end-of-line test positions that drive each motor on a weighted jig and measure acceleration, speed, current, starting voltage and noise. The vibration motors themselves are covered on the Vibration motor (ERM core) page; industrial robot arms used in assembly on the Assembly robot page; silicone moulding of the device body, battery charging and complete appliance lines (such as the Automated refrigerator assembly line and Automated dishwasher production line pages) are outside this page.
CNFX editorial research · Sources checked October 12, 2026 · 4 sources
Cam-driven rotary dial: how precisely each nest arrives under the pressing tool
A cam indexing table moves the dial plate through a fixed number of stops per revolution. WEISS gives its TC150T an indexing precision of 60 arcsec (±30″) for 2 to 12 stations and 90 arcsec (±45″) for 16 to 24 stations, 0.01 mm axial run-out of the drive flange at Ø 150 mm, 0.01 mm radial run-out of the output flange, and a recommended maximum external dial plate of about 880 mm. [1]
Editorial calculation: an angular error becomes a placement error at the nest radius. At a 300 mm nest radius, ±30″ is 300 × 30 / 206,265 ≈ ±0.044 mm; at the 440 mm rim of an 880 mm plate it is about ±0.064 mm, and with 16 or more stations (±45″) about ±0.096 mm. [1] Compare these figures with the clearance between the motor and its holder before relying on the dial alone; tighter work needs a locating pin or lift-off fixture at the station.
WEISS states that TC tables run clockwise, counterclockwise or oscillating, reach up to 220 cycles per minute depending on size, mass moment of inertia and angle, and that the cycle time from start signal to electrical position signal is about 80 to 130 ms longer than the value in its load tables. [1] An optional absolute encoder with WEISS's EF2 control can place 16 virtual cam switches around the plate to start station processes early, and can report which nest is in position over fieldbus or digital I/O. [1]
Give the supplier the motor and holder drawings with their fit, the number of stations, the nest radius and the force each pressing station applies, so dial size and indexing precision can be checked against the part.
02
The 100 g jig test: vibration in G, speed, current, starting voltage and noise
Vibration-motor makers specify their acceptance tests on a weighted jig, so an end-of-line station that is meant to reproduce the motor maker's numbers has to copy the jig mass, mounting and drive. Three published specifications show how much these differ.
Vybronics' method mounts the actuator to vibrate along the 15 mm direction of the jig, places the accelerometer to read that axis, and takes the reading 2 to 3 seconds after the drive is applied, averaging three measurements per vibrator. [4] Editorial calculation: three readings, each taken 2 to 3 s after drive is applied, need at least 6 to 9 s of drive per part if run one after another, so a test station following that method sets a floor on cycle time unless two or more jigs run in parallel. [4]
For noise, Vybronics describes its mechanical-touch measurement, picked up as a vibration signal by an acceleration sensor on a Bako 2120C instrument, as the full-inspection method in mass production instead of the microphone test. [4] Editorial note: a microphone test needs the 25 to 30 dB(A) background quoted by Jinlong and INEED, which a station on a working assembly floor may not reach without an acoustic enclosure. [2][3]
Ask for the test station's jig mass and material, mounting (foam or rigid), sensor axis, drive voltage or waveform, settle time, number of readings and the pass limits, and check them against the motor maker's specification.
03
What the line test cannot show: life, drop and vibration endurance done in the lab
The same specifications define endurance tests that take hours or destroy the part, so they belong to sample qualification, not to the cell.
Editorial note: when the motor is pressed into a holder and soldered or clipped to a board in the cell, the module is no longer the part the motor maker tested; ask whether drop and life tests will be repeated on finished modules from the line.
Test
Published condition
Life
1000 h on-off cycling; speed and current within ±50% of initial, starting voltage 2.5 V DC max afterwards [3]
Drop
Motor on a 100 g plastic jig dropped from 1.5 m onto concrete, twice on each of six faces [2]; on a 160 g dummy jig, 30 drops onto steel from 1.5 m [4]
Vibration endurance
On a 100 g jig, 10 to 55 Hz in three perpendicular directions [2]; on a 160 g jig, 2.2 G, 10 to 55 Hz, 10 min per axis [4]
Storage
96 h at −40 °C, +80 °C, and +40 °C 90% RH, tested after 2 h recovery [2]
04
What to send for a motor-module cell quote
Paste it into your enquiry below or into an email to a maker, then replace every bracket.
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Share this page
Compiled and source-reviewed by the CNFX editorial team.
Each manufacturer above links to the page on that company's own website where the product is listed, with the date we checked it. How we source and review
· Page last updated 13 October 2026
Buyer questions
How precise is a rotary dial table at the nest?
WEISS lists ±30″ for its TC150T at 2 to 12 stations; by editorial calculation that is about ±0.044 mm at a 300 mm radius. [1]
How is a vibration motor's strength tested?
On a weighted jig with an accelerometer; all three specifications reviewed use 100 g for the vibration test: Jinlong lists 0.75 G min, INEED 2.0 G min and Vybronics 1.8 Grms min at resonance for their motors. [2][3][4]
Can noise be checked on every part?
Vybronics uses a mechanical-touch measurement through an acceleration sensor as its full-inspection method in mass production. [4]
Sources and what still needs a direct check
Sources checked 2026-10-12. WEISS publishes data for its own rotary indexing tables; Jinlong Machinery (now trading as Vybronics for some parts) and INEED Electronics publish acceptance and reliability tests for their own vibration motors.