Cleanroom and ESD six-axis assembly arms for electronics and optics: ISO 14644-1 class at speed, ±0.02 mm repeatability and wrist services
Small six-axis arms built for clean, static-sensitive assembly · the ISO 14644-1 class the cleanroom version holds at speed, repeatability at short and long reach, and the air and signal lines brought out at the wrist
Assembling a lens into a camera-module holder or a connector onto a board puts a robot arm a few centimetres above parts that a single particle or a static discharge can scrap. The arms built for this work are small six-axis robots of a few kilograms' payload, offered in a cleanroom version that limits the particles their joints and cables shed and, from some makers, in an ESD version for static-sensitive parts. Choosing one means reading three things from the datasheet: which ISO 14644-1 class the cleanroom version is rated or tested to and at what speed, how repeatability changes between the short and long arm of the same family, and which air, signal and Ethernet lines run through the arm to the gripper.
Compact six-axis articulated robot arms in cleanroom and ESD-protected versions for electronics, optics and other small-part assembly: ISO 14644-1 cleanroom class of the arm, particle-emission qualification at speed and payload, repeatability by arm length, rated and maximum payload, and wrist air, signal and Ethernet routing. Electric linear actuators and slides are covered on the Linear actuators (electric, for automation) page; six-axis arms sized by wrist load and envelope without cleanroom requirements are covered on the Robotic manipulator page, wet food-area arms on the Robotic arm assembly for wet beverage and food packing areas page, and robot choice for screwdriving, insertion and dispensing on the Assembly robot page. Wafer-handling vacuum robots, SCARA and delta robots, and grippers sold alone are outside this page.
CNFX editorial research · Sources checked October 13, 2026 · 3 sources
ISO Class 3 on the datasheet, ISO Class 4 in a test at 50 % and 100 % speed: reading the cleanroom rating of a small arm
The cleanroom figure on a robot datasheet is a class under ISO 14644-1, and it belongs to a particular model, option and test condition. The three documents below show how far the same label can move.
Fraunhofer IPA counted particles from 0.1 µm to 5.0 µm with LasAir optical particle counters and states that its statement applies only to the named product in its original state, with transport damage, incorrect installation, oil leakage, ageing and corrosion able to change the result; the statement is valid for five years. [3] The Gen2 arm it tested is a different variant from the two IRB 1200 versions on ABB's datasheet, so the ISO 3 option and the ISO 4 test result cannot be compared as the same robot. [2][3]
For a buyer, the practical point is to ask for the qualification document of the exact variant, and to check that it was measured at the speed and payload the cell will run, not only at rest.
Arm
Cleanroom statement
Condition or note
Epson C4 (600 mm) and C4L (900 mm)
Cleanroom & ESD version complying with ISO Class 3 (ISO 14644-1) and older Class 10, defined as fewer than 10 particles of 0.1 µm per 28,317 cm³ (1 cft) [1]
ABB packages it with Food Grade Lubrication (NSF H1) and IP67; the lubricant option is listed only with the IRC5 controller [2]
ABB IRB 1200-8/0.9 Gen2, tested by Fraunhofer IPA
ISO Class 4 at 50 % and at 100 % of maximum velocity; overall result 4 [3]
Tested in an ISO 1 room with 0.45 m/s vertical laminar flow, 22 °C ± 0.5 °C, 45 % ± 5 % RH, 8 kg payload, each axis operated separately, 1–3 s pauses [3]
Give the cleanroom class of the assembly area, the speed and payload the arm will run at, whether the parts are static-sensitive, and ask for the particle-emission statement or test report of the exact model and option.
02
±0.02 mm at 600 mm, ±0.03 mm at 900 mm and ±0.05 mm at 1400 mm: repeatability, rated payload and cycle time by arm length
Within one family, the longer arm buys reach at the cost of repeatability and cycle time. For placing a lens or a fine-pitch part, the shortest arm that reaches every station is the one to price first.
Epson states its cycle times for a round-trip arch motion of 300 mm horizontal and 25 mm vertical with path coordinates optimised for speed; the C4 allows 0.15 kg·m² of inertia at joints 4 and 5 and 0.1 kg·m² at joint 6. [1] ABB gives an acceleration time of 0.06 s from 0 to 1 m/s and a maximum TCP acceleration of 35 and 36 m/s² for its two variants. [2]
Editorial calculation: the C4L's 0.47 s cycle is about 27 % longer than the C4's 0.37 s (0.47 ÷ 0.37 ≈ 1.27), and its repeatability band is 1.5 times wider (0.03 ÷ 0.02). Adding the six joint motor ratings Epson lists for the C4 gives 1,100 W (400 + 400 + 150 + 50 + 50 + 50); ABB lists 0.39 kW power consumption for the IRB 1200. The two are different quantities (installed motor power against consumption), so they show scale, not efficiency. [1][2]
State the furthest station the arm must reach, the gripper plus part mass and its inertia about the wrist, the placement tolerance, and the target cycle time with its motion path.
03
Air lines, signal pins and Ethernet run through the arm to the gripper
In a cleanroom cell, hoses and cables strapped along the outside of the arm shed particles and snag. These arms bring services through the structure to the wrist; the counts below decide which gripper, vacuum and camera can be fitted without external dress packs.
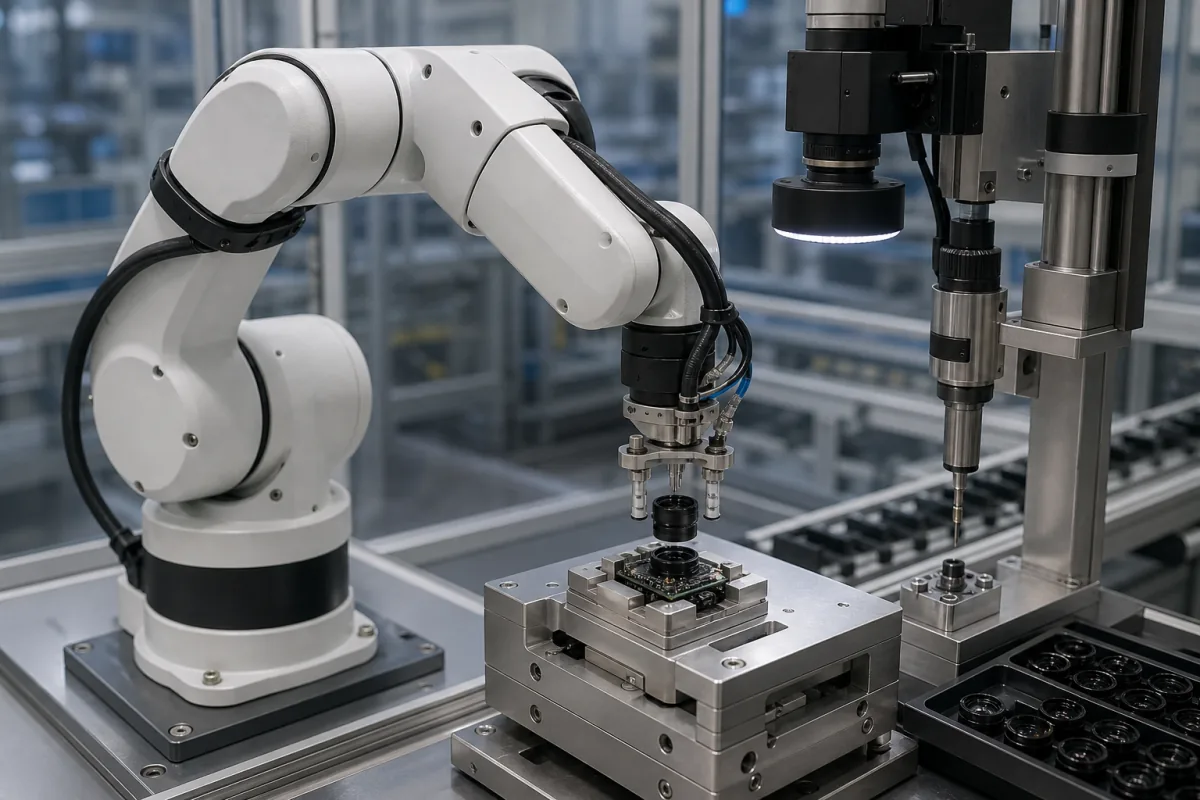
The picture above shows this kind of cell: a white compact six-axis arm holding a lens with a three-finger gripper over a camera-module nest, with a ring-lit camera and a screwdriver spindle on a separate column and lens trays beside it. A vacuum or pneumatic gripper uses the wrist air lines, and a camera or force sensor uses the signal or Ethernet lines, so the counts in the table limit the end-of-arm tooling.
Editorial calculation: an Epson C4 cell with one double-acting gripper and one vacuum cup uses three of its four Φ4 mm lines, leaving one spare; the C8's two Φ6 mm lines would already be full. [1]
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Share this page
Compiled and source-reviewed by the CNFX editorial team.
Each manufacturer above links to the page on that company's own website where the product is listed, with the date we checked it. How we source and review
· Page last updated 13 October 2026
Buyer questions
What cleanroom class do small six-axis assembly robots reach?
Epson rates its C4 and C8 cleanroom versions at ISO Class 3 and the long C8XL at ISO Class 4; ABB lists an ISO class 3 option for the IRB 1200, while Fraunhofer IPA classed an IRB 1200-8/0.9 Gen2 at ISO 4 at full speed. [1][2][3]
Does repeatability change with arm length?
Yes. Epson gives ±0.02 mm for the 600 mm C4 and ±0.03 mm for the 900 mm C4L, and ±0.05 mm for the 1400 mm C8XL; ABB gives 0.02 mm and 0.025 mm for its 0.7 m and 0.9 m IRB 1200. [1][2]
How was the robot's particle emission tested?
Fraunhofer IPA ran the arm in an ISO 1 room with vertical laminar flow at 0.45 m/s, at 50 % and 100 % of maximum velocity with an 8 kg payload, counting particles from 0.1 µm to 5.0 µm. [3]
Which services run through the arm to the gripper?
Epson's C4 has a 9-pin connector and four Φ4 mm air tubes; ABB's IRB 1200 has 10 signals, Ethernet and four 5 bar air lines routed internally. [1][2]
Sources and what still needs a direct check
Sources checked 2026-10-13. Three documents from three publishers: Epson's robot specifications catalog, ABB's IRB 1200 datasheet, and Fraunhofer IPA's particle-emission statement of qualification for an IRB 1200 Gen2 arm.