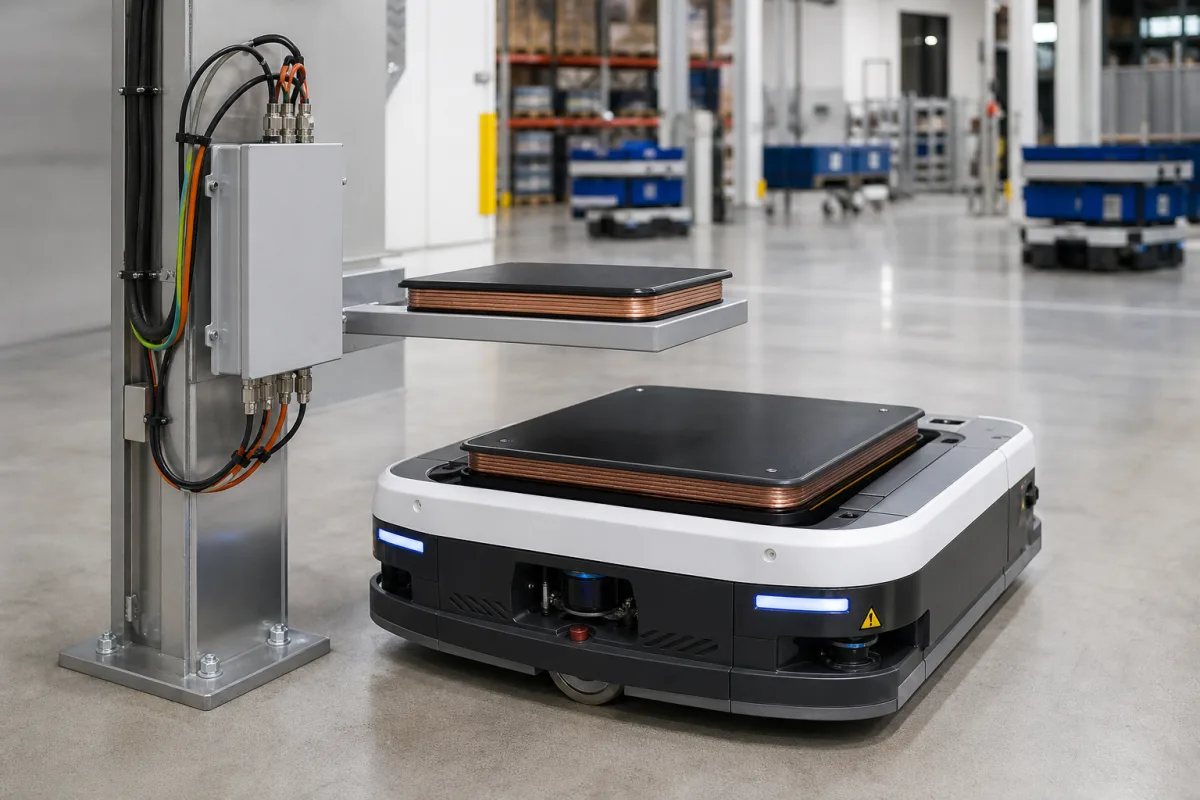
Inductive charging module for AGVs and mobile robots: a stationary pad and an onboard receiver at a 15–40 mm gap
Inductive charging pads for AGVs, AMRs and forklifts · a gap of tens of millimetres instead of a car's ground clearance, low battery voltage at high current, and docking tolerance at the charging spot
Automated guided vehicles and mobile robots charge in short stops at fixed points during the shift, so their wireless chargers are built around a different set of numbers from car chargers. The transmitter pad sits on a wall, post or floor and the receiver on the vehicle's side or underside, a few tens of millimetres apart. The batteries are low-voltage — the systems reviewed here charge packs between 12 and 60 V at up to 60 A — so the receiver electronics carry high current, and the gap changes with load because the chassis sinks when the vehicle is loaded. What a buyer has to pin down is the gap range the pad works over, the position tolerance at the stop, the current at the battery voltage actually used, and how the charger talks to the vehicle and fleet software.
Inductive charging modules for AGVs, autonomous mobile robots, automated forklifts and similar industrial vehicles: stationary transmitter units with charging pads or antenna coils, onboard receiver coils and charger electronics, rated from hundreds of watts to a few kilowatts at gaps of a few tens of millimetres. Wireless charging for electric cars and commercial road vehicles is covered on the Automotive wireless power transfer system page; receiver coils for Qi phone and wearable charging on the Receiver coil assembly for Qi wireless charging page. Rail-guided contactless power lines along a track are outside this page.
CNFX editorial research · Sources checked October 12, 2026 · 3 sources
A 5–25 mm gap that moves with the load: tightly coupled pads under an AGV chassis
Lu, Zhang, Zhu, Diao, Gong, Zhang and Mi contrast the two cases in IEEE Transactions on Industrial Electronics: electric-car chargers transfer across about one hundred millimetres of ground clearance with a coupling coefficient below 0.30, while an AGV chassis clearance is within tens of millimetres, which makes the system tightly coupled. [1] In a heavy-duty AGV the empty and fully loaded conditions change the gap, and in their design example it varies from 5 to 25 mm; both the coil self-inductance and the coupling coefficient fall sharply as the gap widens, which is what makes compensation design harder than in a loosely coupled system. [1]
Editorial calculation: 2.06 kW in and 1.78 kW out leaves about 280 W of loss in the converter and coupler, and 1.78 kW ÷ 24 V ≈ 74 A, matching the 73.8 A charging current the authors report. The paper notes the coupler on one side sits close to the ferrite plate on the other, so a relative movement changes inductance and coupling strongly; ask a supplier for output power at the minimum and maximum gap the vehicle will present, not only at nominal. [1]
Prototype item (IEEE TIE 2019)
Value
Magnetic coupler
220 × 200 × 10 mm in the abstract; receiver 220 × 220 × 10 mm in the design section [1]
Integrated LCC, chosen for robustness to gap variation and low high-order harmonics [1]
Result at 15 mm gap
2.06 kW in from 300 V DC; 1.78 kW out to a 24 V battery; 73.8 A; 86.1% DC–DC efficiency [1]
Gap 5 to 25 mm
Power variation within ±36.7%; efficiency not significantly affected [1]
02
Battery voltage and current: 3 kW at 15–60 V and 60 A, 1 kW at 12–58.4 V and 36 A
The two commercial systems below are specified at the battery: rated power, the battery voltage window and the maximum charging current. The current limit decides how much of the rated power reaches a low-voltage pack.
Editorial calculation: 3,000 W ÷ 60 A = 50 V, so on a 24 V pack the 60 A limit allows about 1.44 kW from the etaLINK 3000; 1,000 W ÷ 36 A ≈ 27.8 V, so the OC-1000 reaches its full 1 kW only on packs above about 28 V. Wiferion states the etaLINK reaches efficiency of up to 93% in energy transfer and that two or three units can be combined for 6 kW or 9 kW. [2]
Editorial note: quote the battery's nominal and maximum charge voltage and the charge current you need; a rated power figure alone does not say what a 24 V vehicle receives.
03
Docking at the pad: approach direction, start time and the data link to the vehicle
Wiferion's system pairs a stationary transmitter unit, made up of a wallbox and charging pad, with receiving electronics installed in the vehicle; charging starts in less than a second when the vehicle stops at the pad, from any direction of approach, and different vehicles can use the same charging pad. [2] Battery status and energy data go to fleet management over an integrated CAN interface, and management and telemetry data cross to the pad contactlessly through infrared interfaces. [2] An elongated etaLINK 3000R version is offered for mounting in the side of flat vehicles. [2]
WiBotic splits the stationary side into a transmitter box and a separate transmitter antenna coil connected by a short coaxial cable, so the TR-1000 box (373.26 × 301 × 108.1 mm) can be wall-mounted or set on a floor stand with the coil placed where the robot stops. [3] Its onboard charger is configured per robot for battery chemistry, voltage and current; the TR-1000 has an Ethernet port for WiBotic's fleet software or network API, and transmitters and onboard chargers are interoperable one-to-one, one-to-many or many-to-many, with the system limited by the lower-rated of the two. [3]
04
Data for an AGV inductive charging enquiry
Paste it into your enquiry below or into an email to a maker, then replace every bracket.
Vehicle: [AGV, AMR or forklift; mounting position for the receiver — underside or side]
Battery: [chemistry; nominal and maximum charge voltage; charge current]
Gap: [minimum and maximum gap empty and loaded; lateral stopping accuracy]
Power: [power at the battery; charging stops per shift and dwell time]
Site: [mains supply; wall, post or floor transmitter; IP rating; pad shared by more than one vehicle]
Data: [CAN, Ethernet or other link to the vehicle and fleet manager]
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Share this page
Compiled and source-reviewed by the CNFX editorial team.
Each manufacturer above links to the page on that company's own website where the product is listed, with the date we checked it. How we source and review
· Page last updated 13 October 2026
Buyer questions
What gap does an AGV wireless charger work across?
Wiferion gives an optimum distance of 15–40 mm for etaLINK 3000; an IEEE prototype was designed for a 5–25 mm gap that changes between empty and loaded vehicle. [2][1]
Why is current more important than power for a 24 V robot?
Chargers are current-limited: etaLINK 3000 is 3 kW and 60 A, about 1.44 kW at 24 V; WiBotic's OC-1000 is 1 kW and 36 A, full power only above about 28 V. [2][3]
How efficient is inductive AGV charging?
Wiferion states up to 93% energy transfer efficiency; a 1.78 kW prototype reached 86.1% DC–DC efficiency into a 24 V battery at a 15 mm gap. [2][1]
How precisely must the vehicle stop?
Wiferion specifies ±30 mm position tolerance for etaLINK 3000 and says the pad can be approached from any direction. [2]
Sources and what still needs a direct check
Sources checked 2026-10-12. Gap behaviour, coupler build and measured efficiency come from the IEEE Transactions on Industrial Electronics AGV prototype paper; distance, tolerance and ratings from Wiferion's etaLINK 3000 product page; transmitter and onboard charger ratings from WiBotic's TR-1000 and OC-1000 pages.