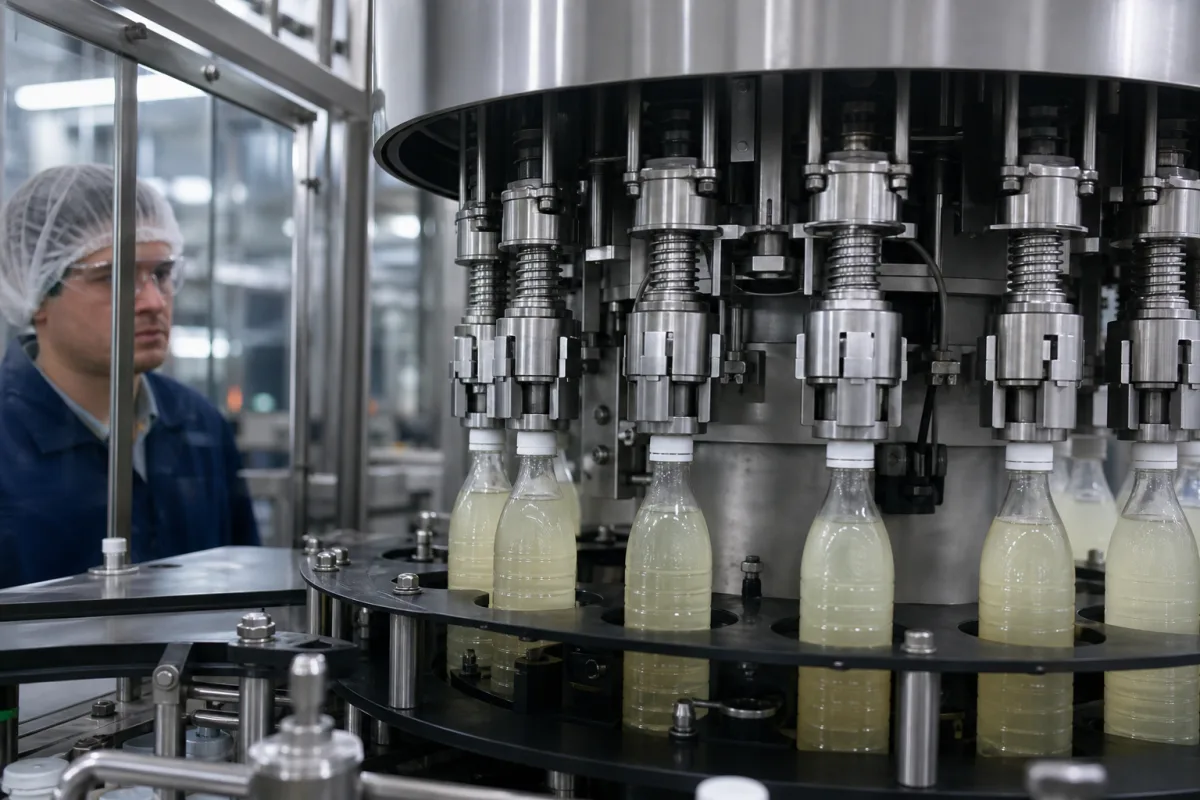
Servo-driven rotary capping head: the electronically controlled screw-capping head that sets torque and speed in software, follows the cap down the thread and reports every closure
Servo-driven rotary capping head · one servo motor per head on the capper turret, torque set in 0.01 N·m steps, motor current versus torque sensor, a servo-screw head that replaces the lifting cam, and per-cap torque waveforms
On a rotary screw capper, each head picks a cap, spins it onto the bottle neck as the turret carries the bottle round, and stops at the right torque. In a mechanical head the stopping point is a clutch set by hand; in a servo-driven head each spindle has its own servo motor, so torque, speed and the tightening profile are numbers in the controller and can change between products without touching the head. The turret in the picture shows the rotary arrangement: a ring of spring-loaded heads above PET bottles in a starwheel. This page covers the servo-driven version of that head: how its torque is set and measured, how one design replaces the lifting cam with a servo screw, and how each closure is checked.
Servo-driven (electronically controlled) screw-capping heads for rotary and in-line cappers: the per-head servo motor or servo driver, torque setting and feedback, speed profile, vertical stroke and the data recorded for each cap. Mechanical capping spindles with magnetic or hysteresis torque clutches are covered on the Capping spindle page; jaw-type chucks for tamper-evident caps on the Jaw-type capping head page; complete rotary and in-line screw cappers with their output and head count on the High-speed rotary bottle capping machine page; crown, ROPP and cork closing machines on the Automated bottle capping machine for crimped, rolled-on and corked closures page; and aseptic capping turrets on the Aseptic capping unit page.
CNFX editorial research · Sources checked October 13, 2026 · 3 sources
Torque as a set point: 0.5 to 10.00 N·m in 0.01 N·m steps, and why motor current is not the torque on the cap
Nidec Drive Technology sells the BRX series as a servo driver to be built into capping machines, made up of a driver unit, a setting display and a controller unit. Its published settings show what an electronically controlled head can be told to do. [1]
Where the torque is measured matters. In EP 1 205 430, Seiko Corporation and British Autogard note that when a servomotor turns the head, the signal monitored is the motor's output current rather than the torque applied to the cap and container, so mechanical losses in the motor and head are included and the value is less precise; fitting a torque detector and monitor on every head instead adds cabling through the rotating turret and cost. Their answer is a torque-limiting clutch on each head with a radio transmitter that sends the tightening value off the turret. [2]
Editorial calculation: at Nidec's 500 rpm upper speed a head turns 8.3 times a second, so the roughly 3 turns that Toyo Seikan gives for tightening a cap take about 0.36 s; at 50 rpm the same 3 turns take 3.6 s. [1][3]
Torque sensor on the output-shaft side; tightening controlled to the set torque [1]
Speed change under load
ARX continuously variable transmission changes speed with load torque, allowing a small motor [1]
Acceptance
Maximum output torque displayed at the end of tightening and judged against stored upper and lower limits; fault signal output [1]
Networking
Up to 10 controllers per setting device over RS-422; printer, RS-232C and analog outputs [1]
Ask whether the head's torque value comes from a torque sensor on the spindle or from motor current, what the setting resolution and repeatability are, and how accept/reject limits are stored and changed per product.
02
Following the cap down the thread: a 10 mm-lead servo screw for a 3 mm cap lead instead of a lifting cam
Toyo Seikan's EP 1 757 555 describes the two older head types first. In a mechanical head, a planetary gear rolling on a fixed gear turns the chuck through a torque limiter, a magnetic limiter for example, and a cam follower on a lifting cam lowers the chuck as the cap tightens; a buffer above the chuck absorbs the stroke difference from turning more than the roughly 3 turns needed. In a servo head of the earlier type, a servo motor replaces the planetary gear and torque limiter, so the chuck speed and the tightening torque can be changed by the servo motor during operation, but the lifting cam remains. [3]
The patent's objections to the cam are cost (cam and follower machined from wear-resistant material), noise and dust from exposed gear and cam contacts, grease that can spatter into an area that must stay clean for filled containers, and the need to change the fixed gear or cam when the cap's thread pitch changes. Its head lowers the chuck through a screw mechanism driven by the servo motor itself, inside a fixed case that keeps debris in; a stroke-difference absorption section takes up the mismatch between screw and cap thread, and a one-way clutch lets the motor lift the chuck by turning backwards without driving it. [3]
In the patent's example, the screw shaft has a 10 mm lead and the cap thread 3 mm (or 6 or 9 mm), so the screw descends 10 mm per motor turn while the chuck descends 3 mm. Editorial calculation: over 3 tightening turns the screw travels 30 mm and the cap 9 mm, so the absorption section has to take up 21 mm of difference. [3]
Give the supplier the cap thread lead and number of turns to seal, and ask how the head handles the stroke: lifting cam, servo screw or another mechanism, and what has to change for a different cap.
03
Checking each closure on a 12 to 18 head turret: torque waveforms read while the turret turns
Seiko and British Autogard describe rotary cappers with 12 to 18 chuck heads on a disc that turns, each head tightening its cap within a section from a starting position to an ending position. A receiver outside the turret picks up each head's tightening value at the end position, or continuously between start and end, and a control unit compares it with a reference torque; a container within the appropriate range continues down the line. [2]
Reading the whole tightening curve, not just the final value, lets the controller compare each cap with a basic torque-variation pattern: a cap that reaches the prescribed final torque but did not follow the pattern, was put on improperly, or is itself faulty can be found and removed, failures that the patent says are not easily checked visually. [2] Nidec's driver records the maximum torque at the end of each tightening and outputs a fault signal when it falls outside the stored limits. [1]
Ask what the head records for each cap (final torque, peak, angle, full curve), how a rejected container is tracked to the reject station, and how the data leave the turret.
04
What to send for a servo capping head
Paste it into your enquiry below or into an email to a maker, then replace every bracket.
Closure: [cap type and diameter; thread lead; turns to seal; liner]
Torque: [application torque and tolerance; removal torque target]
Speed: [heads on the turret; bottles per minute; tightening section angle]
Drive: [servo per head or retrofit to existing turret; torque sensor or motor current]
Stroke: [lifting cam or servo screw; cap height range]
Data: [values recorded per cap; reject handling; line interface]
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Share this page
Compiled and source-reviewed by the CNFX editorial team.
Each manufacturer above links to the page on that company's own website where the product is listed, with the date we checked it. How we source and review
· Page last updated 13 October 2026
Buyer questions
What torque range can a servo capping drive set?
Nidec's BRX servo driver for capping machines sets 0.5 to 10.00 N·m in 0.01 N·m steps at 50 to 500 rpm, with a torque sensor on the output shaft. [1]
Is servo motor current an accurate measure of capping torque?
Seiko and British Autogard note that servo output current includes mechanical losses in the motor and head, so it is not the torque applied to the cap. [2]
Can a servo capping head work without a lifting cam?
Toyo Seikan's patented head lowers the chuck through a servo-driven screw, absorbing the difference between the 10 mm screw lead and a 3 mm cap thread. [3]
Sources and what still needs a direct check
Sources checked 2026-10-13. Torque and speed settings come from Nidec Drive Technology's BRX product data; the current-versus-torque problem and turret monitoring from Seiko Corporation and British Autogard's EP 1 205 430; head construction with and without a lifting cam from Toyo Seikan's EP 1 757 555.