Editorial Technical Reference
Torque transducer
Static flange measurement
Read the bridge signal in newton-metres. Match the measuring range, mounting and calibration to the torque you actually need to resolve.
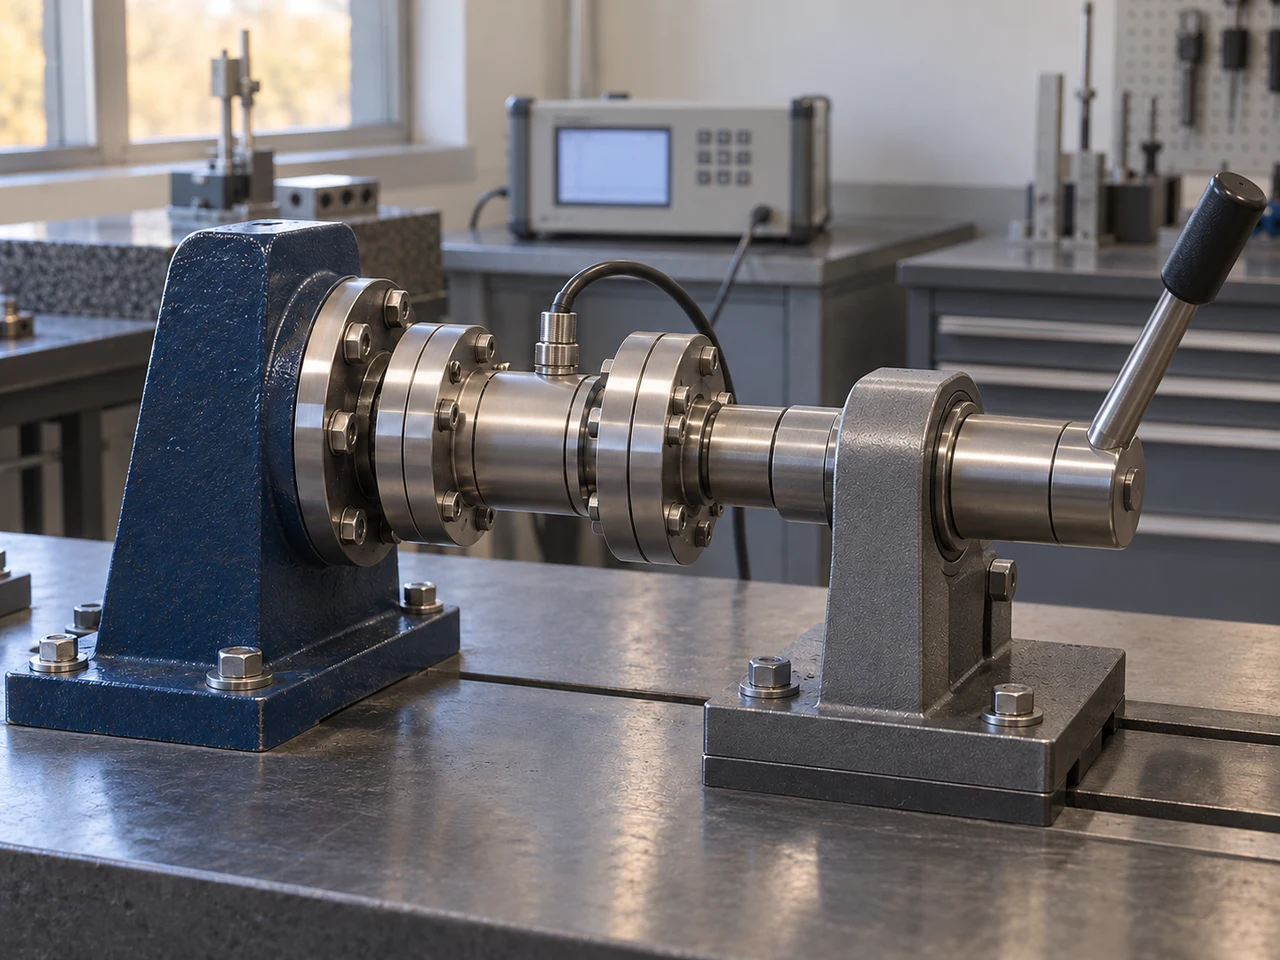
Static flange measurement
Read the bridge signal in newton-metres. Match the measuring range, mounting and calibration to the torque you actually need to resolve.
01
Torque twists an elastic measuring body; attached strain gauges respond through a change in resistance. A bridge and its readout convert that response into a torque indication. HBK explains this principle and distinguishes rotating from non-rotating measurement; varying torque can also occur without rotation. [3]
| Functional component / BOM reference | Role and evidence boundary |
|---|---|
| Flanges and elastic body | Carry the applied torque. ZMFNJ is a non-rotating, flange-to-flange design; its published construction is nickel-plated alloy steel. Its outline drawing changes with capacity. This is not a universal shaft or bolt specification. [1] |
| Strain gauges and bridge | Sense the body’s deformation electrically. The ZMFNJ drawing shows the bridge connection; its gauge-foil alloy, adhesive and replacement part numbers are not published. [3] [1] |
| Excitation, amplifier and readout | Provide bridge power and resolve the small output. ZMFNJ specifies an unamplified mV/V signal; an included internal conditioner or 0–10 V output is not established. Specify the external measurement chain and calibrate it together. [1] [2] |
| Body protection and sealing | Protect the sensing assembly. ZMFNJ lists IP66 with hermetic sealing optional; it does not identify a separate stainless-steel or aluminium enclosure. Ask for the ordered sealing construction. [1] |
| Connector and cable | Carry excitation and signal: the drawing assigns red +excitation, black −excitation, green +signal and white −signal, plus shield. Confirm the supplied connector pinout; its contact and shell materials are not specified. [1] |
This is a functional assembly reference, not a production parts list. Obtain the selected capacity’s drawing, fastening requirements and electrical connection sheet before integration.
02
Anhui Zhimin’s ZMFNJ family lists capacities from 5 to 10,000 Nm for non-rotating clockwise and counter-clockwise measurement. Those are family limits, not the working range of every unit. The following values belong to its undated two-page datasheet, checked 10 October 2026. [1]
2.0 mV/V × 10 V excitation = a nominal 20 mV span at rated torque, relative to the unloaded output. Use the individual calibration sensitivity for measurement.
On a 500 Nm unit, ±0.2% RO non-linearity = ±1.0 Nm; ±0.1% hysteresis = ±0.5 Nm.
Select the amplifier’s input range and effective resolution for the desired Nm increment. NPL evaluates the actual indication, including fluctuating readings, rather than relying on a nominal digit count alone. [2]
| Specification | Published ZMFNJ value and purchasing meaning |
|---|---|
| Rated torque | 5–10,000 Nm family; order a specific capacity and its matching flange drawing. No continuous rotational-speed rating is supplied. [1] |
| Accuracy class | No calibration class or overall system uncertainty is declared in this sheet. The individual figures below are not a combined accuracy rating. [1] |
| Non-linearity | ±0.2% of rated output (RO), not ±0.2% of the reading. [1] |
| Hysteresis | ±0.1% RO. Increasing and decreasing loading must be distinguished in calibration. [1] [2] |
| Non-repeatability | ±0.05% RO. Repeated readings under the same conditions differ from reproducibility after remounting. [1] [2] |
| Rated output and zero balance | 2.0 mV/V; unloaded zero balance ±1% RO. Record the initial zero before taring. [1] [2] |
| Excitation voltage | 10 V recommended, 15 V maximum. Confirm a compatible bridge supply and amplifier. [1] |
| Bridge resistance | Input 380 ±10 Ω; output 350 ±3 Ω. These are separate values, with published tolerances. [1] |
| Insulation resistance | 5,000 MΩ is listed; the test voltage is not given. Request the test conditions instead of assuming a 50 V test. [1] |
| Temperature ranges | Compensated −10 to +40 °C; operating −20 to +60 °C. The wider operating range does not extend the stated compensation interval. [1] |
| Temperature effect on zero | ±0.0026% RO/°C, labelled “Min. dead load output” in the sheet. [1] |
| Temperature effect on sensitivity | ±0.0015% RO/°C as printed. Confirm the maker’s interpretation and temperature test report for a partial-load uncertainty assessment. [1] |
| Ingress protection | IP66; hermetic sealing is an option. Confirm the actual connector and seal configuration. [1] |
| Material | Nickel-plated alloy steel for the published transducer. Individual internal materials are not itemised. [1] |
The sheet also lists 30-minute creep and 30-minute zero return at ±0.03% RO each. They describe different loaded and unloaded behaviour; neither is a permanent correction that can be ignored after a single tare. [1] [2]
03
Worked example: a 500 Nm ZMFNJ, with temperature changing from 20 to 40 °C, both inside its compensated interval. The values below are separate datasheet-based magnitudes, not measured results or a complete uncertainty budget. [1]
The sheet lists safe overload at 150% and ultimate overload at 200% of rated capacity. These limits do not supply calibrated measurements above rated torque or qualify repeated shock loading. Specify normal torque, measurable peaks, reversals and accidental loads separately; obtain the manufacturer’s load limits for the actual installation. [1]
The ±1% RO initial zero balance corresponds to ±5 Nm on this example. Taring can remove that initial indication, but temperature drift, creep recovery and zero shift after reversing torque still matter. NPL treats these as separate tests and records untared zeros. [1] [2]
The table excludes reference torque, readout, mounting and calibration uncertainty. NPL’s calibration deviations can be relative to the output change at the actual test point, whereas this maker uses rated output. Keep those denominators explicit; a sum or root-sum-square of catalogue limits alone is not an established expanded uncertainty. [2]
| Error source | % of rated output | Nm on a 500 Nm unit |
|---|---|---|
| Non-linearity | 0.2% | 1.0 |
| Hysteresis | 0.1% | 0.5 |
| Non-repeatability | 0.05% | 0.25 |
| Zero drift, 20 °C × 0.0026%/°C | 0.052% | 0.26 |
| Sensitivity drift, 20 °C × 0.0015%/°C | 0.03% | 0.15 at full load |
04
NPL notes that in practice a transducer also sees bending and parasitic forces, and that their influence depends on the design [2].
ZMFNJ publishes no measurement bandwidth or fatigue envelope here. NPL’s electronic frequency-response test is not proof of the complete mechanical installation’s dynamic response. Ask for application-specific evidence if the torque changes rapidly. [1] [2]
05
NPL Good Practice Guide 107 (2008), printed pages 2–5, gives the following basic procedure. Agree the required test scope with the calibration laboratory; this summary is not a substitute for the selected calibration method. [2]
Record part and serial numbers of transducer, lead and readout, and the temperature [2].
Allow at least one hour of thermal stabilisation, longer after a large temperature change [2].
Apply three preloads to the maximum calibration torque on first mounting, and one after each remounting. Maximum calibration torque is not permission to apply the sensor’s overload limit. Record the untared zeros. [2]
Use at least five equally spaced increasing torque points including the maximum calibration torque; take readings after at least 30 seconds, with consistent settling conditions. Include decreasing series where required to evaluate hysteresis. [2]
Use three symmetric mounting orientations for flange/shaft transducers, four for square drives. This checks reproducibility under remounting; it is not a test of continuous shaft rotation. [2]
NPL’s 2008 guide cites historical editions. The current catalogue entries checked here are BS 7882:2017 and DIN 51309:2022-08. Only their public catalogue information was reviewed, not the paid clauses. Specify the method and edition, direction, points, uncertainty and laboratory scope on the quotation. [5] [4]
06
Paste it into your enquiry below or into an email to a maker, then replace every bracket.
Application: non-rotating flange measurement; quantity [ ]
Torque: working [ ] Nm; smallest change to resolve [ ] Nm; measurable peak [ ] Nm
Loading: CW / CCW / alternating [ ]; rise time or frequency [ ]; accidental overload [ ]
Uncertainty required: [ ] Nm at test points [ ]; temperature interval [ ] °C
Mechanics: capacity-specific flange drawing [ ]; couplings [ ]; axial/radial/bending loads [ ]
Signal chain: transducer [ ]; excitation [ ]; amplifier/readout [ ]; filter settings [ ]
Cable and connector: length [ ]; pinout and shield termination [ ]
Environment: compensated temperature needed [ ]; moisture/cleaning exposure [ ]; sealing option [ ]
Calibration: agreed method and edition [ ]; CW/CCW points [ ]; remounting and reversal checks [ ]
Certificate: system serial numbers, measured results and uncertainty; accredited scope if required [ ]
Supply: sensor / amplifier / cable / couplings / installation drawing [ ]
Acceptable zero change and recheck procedure [ ]
Delivery country [ ]; date [ ]
The two companies below publish torque transducers. Their product tables establish different offerings; they do not establish equivalent accuracy, rotation capability or an independently audited production site.
Publishes the ZMFNJ non-rotating double-flange family and its two-page datasheet. Select the capacity and matching geometry; the mV/V bridge requires a compatible measurement chain. Request the individual calibration evidence rather than treating the catalogue’s non-linearity limit as total accuracy.
Product scope checked 2026-10-10
Lists T601-01 through T601-05 torque transducers. Its table places IP65 in the T601-04 material row and repeats 10 in the T601-02 capacity list; some error fields are blank. Request a corrected model sheet, rotational-speed limits where relevant, and the supplied amplifier configuration.
Product scope checked 2026-10-10
Published offices and group entities ↗
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
It specifies nominal output span per volt of excitation at rated torque: 2.0 mV/V gives 20 mV with 10 V excitation. The unloaded offset is separate; use the individual calibration result to set the readout. [1]
For ZMFNJ, ±0.2% RO is the non-linearity specification. On a 500 Nm unit it corresponds to ±1 Nm; it is not a complete accuracy or calibration-class claim. Hysteresis, repeatability, temperature, mounting and readout also need assessment. [1] [2]
NPL’s 2008 guide treats the sensor, cable and readout as a system: allow thermal stabilisation, preload to maximum calibration torque, take stepped readings and repeat after remounting. Agree the method edition, directions, points and uncertainty with the laboratory; remounting is not continuous-rotation qualification. [2]
Misalignment and bending add parasitic loads; flexible couplings and rigid mounting reduce them. [2]
Sources checked 2026-10-12. Standards bodies and regulations define the requirements; manufacturer pages show published ranges for those models only. CNFX does not certify products or suppliers.
Ask for use case, specification boundaries, supplier type, and RFQ preparation information for this product.
Compare manufacturer profiles with relevant product and process capability.