Editorial Technical Reference

End-Effector (Gripper)

This page explains how End-Effector (Gripper) is classified within Machinery and Equipment Manufacturing. Technical values and manufacturer relationships are research references; confirm the current specification and supplier evidence for each order.

Technical Definition & Core Assembly

The terminal component of a robotic manipulator arm designed to grasp, hold, and manipulate objects.
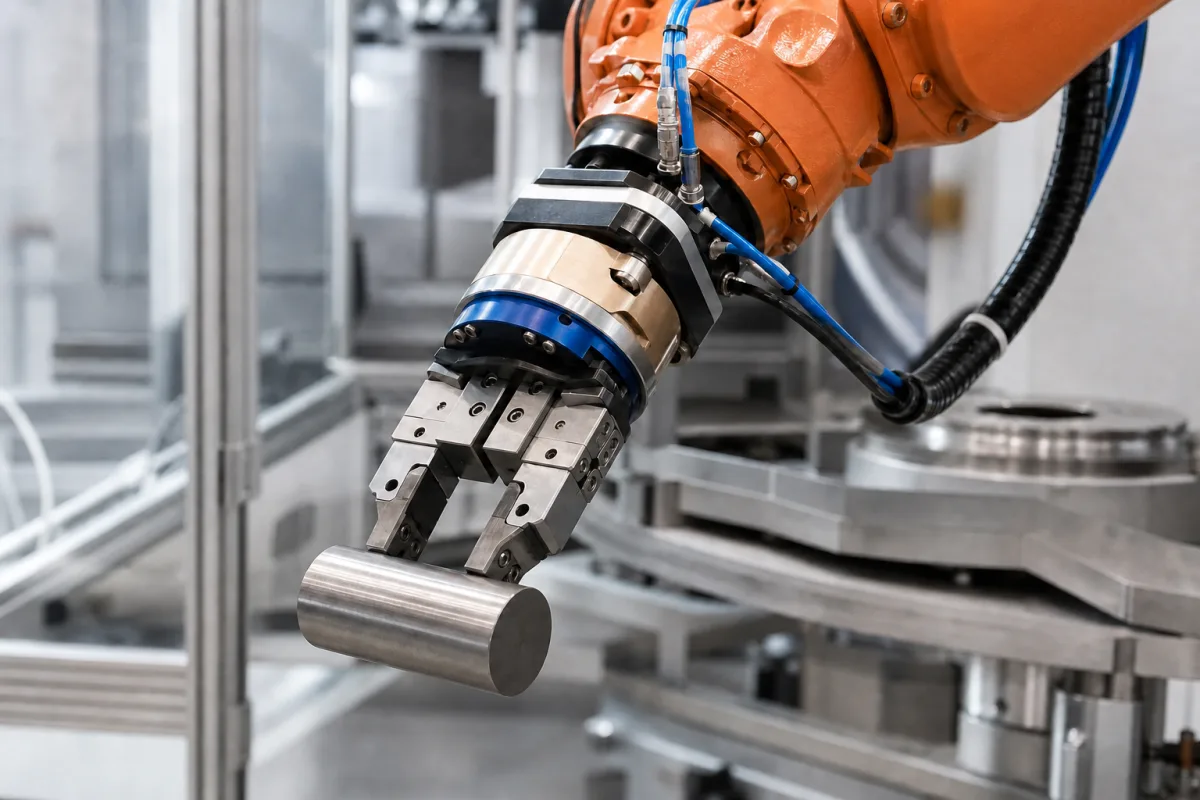
End-Effector (Gripper) in a manufacturing environment
Representative product image. Confirm appearance and specifications with the manufacturer.

Product Specifications

Technical details and manufacturing context for End-Effector (Gripper)

Definition
An end-effector, specifically a gripper, is the device mounted at the end of a robotic manipulator arm that enables physical interaction with the work environment. It serves as the 'hand' of the robot, responsible for the final task of picking, placing, holding, or manipulating objects. Its design and capabilities directly determine the robot's application in tasks such as assembly, packaging, machine tending, and material handling. The gripper typically consists of fingers or jaws, an actuation mechanism, and a mounting interface. The actuation can be pneumatic, hydraulic, or electric, and the motion is transmitted through a linkage system to open or close the fingers. The gripping force, stroke, and repeatability are critical parameters that must match the specific application requirements. The gripper may include sensors for force or position feedback, and its materials are chosen based on the environment and the objects handled. For instance, aluminum alloy and steel are common for industrial use, while stainless steel is preferred for food or pharmaceutical applications. The operating pressure, gripping force, stroke per jaw, repeatability, operating temperature, supply voltage, IP rating, weight, and material are key specifications that need to be verified with the manufacturer for the actual model. Standards such as ISO 9283, IEC 60529, ASTM B221, and AISI 304 are referenced for testing and material specifications, but they do not imply certification or compliance. Always confirm model-specific values and standards with the legal manufacturer or supplier before procurement.
Working Principle
The gripper operates by converting an input signal (typically pneumatic, hydraulic, or electric) into a mechanical motion to open or close its fingers or jaws. This motion applies a controlled force to securely grasp an object. The actuation mechanism (e.g., pneumatic cylinder, electric motor, or servo) drives a linkage system that translates linear or rotary motion into the gripping action. Sensors may provide feedback on grip force or position.
Common Materials
Aluminum Alloy, Steel, Engineering Plastic
Technical Parameters
ParameterTypical rangeNotes & selection driver
Gripping Force50–500 NForce at specified pressure
Stroke per Jaw10–50 mmTotal jaw opening is twice this
Repeatability±0.05 mmAt constant temperatureISO 9283
Operating Temperature-40–85 °CNon-condensing environment
Supply Voltage24 ±10% V DCFor integrated sensors/electronics
IP RatingIP54–IP65IP65 with optional sealingIEC 60529
Weight0.5–5 kgWithout accessories
MaterialAluminum alloy / Stainless steelStainless for food/pharmaASTM B221 / AISI 304

Ranges are indicative industry figures for RFQ preparation, not a supplier commitment. Confirm every value and standard with the legal manufacturer before ordering.

Components / BOM
  • Gripper Body/Housing Part
    Provides structural support and houses the internal actuation mechanism.
    Material: Aluminum Alloy or Steel
  • Actuator (Cylinder/Motor)
    Converts input energy (air pressure, electricity) into mechanical motion.
    Material: Steel, Copper, Magnets
  • Fingers/Jaws Part
    The contact surfaces that directly grasp the object; often customizable.
    Material: Steel, Aluminum, Polyurethane, Rubber
  • Linkage Mechanism
    Transmits and converts the actuator's motion into the opening/closing of the fingers.
    Material: Steel
  • Feedback Sensor Optional
    Reports grip force or jaw position back to the robot controller, on instrumented grippers.

Applied To / Applications

This component is essential for the following industrial systems and equipment:

Industrial Ecosystem & Supply Chain Structure

Complementary Systems
Downstream Applications
Specialized Tooling

Application Fit & Sizing Matrix

Operational Limits
pressure: 0 to 10 bar
other spec: Max grip force: 500 N, Max object weight: 25 kg, Operating speed: 0.1-1.0 m/s
temperature: -40°C to +85°C
Media Compatibility
✓ Metal parts (steel, aluminum) ✓ Plastic components (ABS, polycarbonate) ✓ Packaged goods (boxes, containers)
Unsuitable: Corrosive chemical baths
Sizing Data Required
  • Object dimensions (length/width/diameter)
  • Required grip force (N)
  • Cycle rate (grips per minute)

Reliability & Engineering Risk Analysis

Failure Mode & Root Cause
Gripper misalignment
Cause: Wear in pivot points or mounting hardware, leading to uneven gripping force and potential product damage or dropped loads.
Loss of gripping force
Cause: Degradation of pneumatic seals or hydraulic components, resulting in pressure leaks and insufficient clamping pressure.
Maintenance Indicators
  • Audible hissing or air leaks during operation
  • Visible misalignment or wobble during gripping cycles
Engineering Tips
  • Implement regular alignment checks and torque verification on mounting hardware to prevent progressive wear.
  • Establish a preventive maintenance schedule for seal replacement and pressure system integrity testing before failure occurs.

Indicative industry ranges for design and RFQ preparation. Confirm the exact figures and applicable standard with the manufacturer before specifying.

Compliance & Manufacturing Standards

Applicable Standards
ISO 9409-1:2004 - Mounting interfaces for industrial robots ANSI/RIA R15.06-2012 - Industrial Robots and Robot Systems - Safety Requirements CE Marking - Machinery Directive 2006/42/EC

Quoted from the published standard.

Manufacturing Precision
  • Bore diameter: +/-0.01mm
  • Parallelism of gripping surfaces: 0.05mm
Quality Inspection
  • Dimensional verification with CMM (Coordinate Measuring Machine)
  • Load capacity and repeatability testing

Manufacturers of End-Effector (Gripper)

Manufacturer profiles associated with End-Effector (Gripper).

Sourcing End-Effector (Gripper) from China?
Tell us your specification and target quantity — we will match it against manufacturer records and come back with the factories that fit.
Request manufacturers We manufacture this

Manufacturer listings support early research and capability understanding. They are not certification, ranking, or transaction guarantees.

Share this page
Technical documentation
Request current drawings, revision history, and a signed specification sheet.
Manufacturing capability
Verify equipment lists, process limits, capacity, and representative production evidence.
Inspection readiness
Confirm test methods, calibrated equipment, sampling plans, and traceable reports.
Supplier transparency
Check the legal entity, factory address, ownership, certifications, and direct contacts.

CNFX does not score or rank suppliers. Buyers must verify all claims and documents with the legal manufacturer before ordering.

Supply Chain Compatible Machinery & Devices

Automated Powder Coating System

Integrated industrial system for applying dry powder coatings to metal substrates.

Explore Specs →
Centrifugal Pump Impeller

The centrifugal pump impeller is a critical rotating component that converts mechanical energy from the motor into kinetic energy in fluid systems.

Explore Specs →
High-Precision CNC Laser Cutting Machine

Computer-controlled industrial machine using focused laser beams to cut sheet metal with micron-level accuracy.

Explore Specs →
Industrial-Grade Hydraulic Cylinder Piston Rod

This industrial-grade piston rod is a precision-ground cylindrical component designed for use in hydraulic cylinders.

Explore Specs →

Frequently Asked Questions

What are the typical operating pressure ranges for this gripper?

The operating pressure is listed as 1.0–1.6 MPa. This is a reference range; the actual model must be verified with the manufacturer.

What is the gripping force range?

The gripping force is specified as 50–500 N at the specified pressure. This is a directory reference; confirm the exact force for your application with the supplier.

What is the repeatability of this gripper?

Repeatability is listed as ±0.05 mm at constant temperature, according to ISO 9283. This is a reference value; verify the actual repeatability for the specific model.

What IP ratings are available?

The IP rating is listed as IP54–IP65, with IP65 available with optional sealing, per IEC 60529. Confirm the rating for your environment with the manufacturer.

Data Basis

Editorial classification, named public sources where available, and source-reviewed manufacturer records.

Preliminary Technical Classification
This page supports structured research, RFQ preparation, and supplier evaluation. It does not replace buyer-led supplier qualification, standards review, or technical approval.
Buyer enquiry

Request manufacturing insight for End-Effector (Gripper)

Ask for use case, specification boundaries, supplier type, and RFQ preparation information for this product.

Where it goes
Straight to the CNFX editorial desk, and to the manufacturer if this product is linked to a claimed profile. Nothing is broadcast to a supplier list.
Your details stay here
We do not sell or rent enquiry data, and we do not add you to a mailing list. Used only to answer this request.
No commission, no middleman
CNFX is a directory. We take no cut of any order and never negotiate on a supplier's behalf.
What we don't claim
A listing is not an endorsement. Qualify every supplier and verify every figure yourself before ordering.

Your business information is used only to process this request.

Thank you! Your message has been sent. We'll respond within 1–3 business days.
Sorry, we couldn't send your message. Please try again, or email us at [email protected].

Need to Manufacture End-Effector (Gripper)?

Compare manufacturer profiles with relevant product and process capability.

Previous Product
Z-axis Ram/Spindle
Last Product
Get QuotesChat