Automated Ingot Stacking and Palletizing System
View system integration details
This page explains how Robotic Manipulator Arm is classified within Machinery and Equipment Manufacturing. Technical values and manufacturer relationships are research references; confirm the current specification and supplier evidence for each order.
A programmable mechanical arm used for precise positioning and manipulation of objects in industrial automation systems.
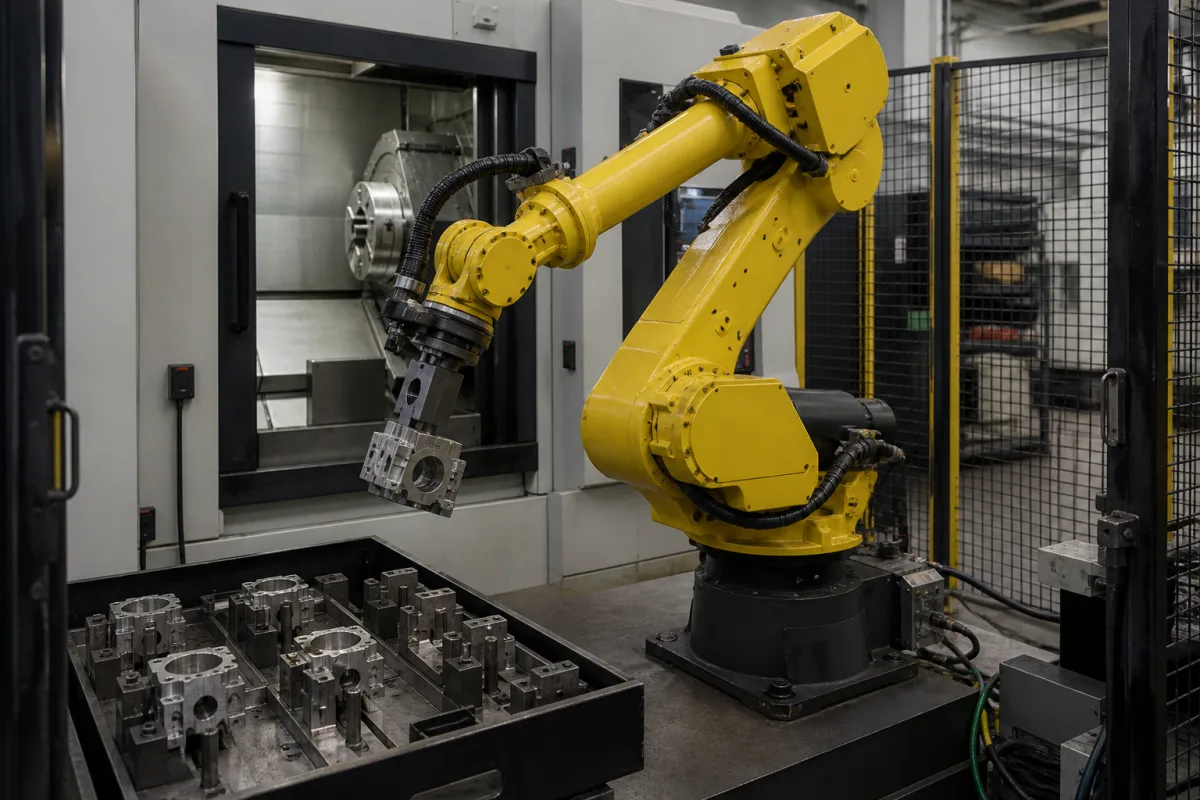
Technical details and manufacturing context for Robotic Manipulator Arm
| Parameter | Typical range | Notes & selection driver |
|---|---|---|
| ReachRequired | 600–1500 mm | Maximum horizontal distance from the robot base to the end-effector |
| Degrees of FreedomRequired | 4–6 | Number of independent axes of motion (joints) |
| RepeatabilityRequired | ±0.05–±0.1 mm | Positional accuracy for returning to a taught pointISO 9283 |
| Payload Capacity | 3–20 kg | Maximum weight the arm can handle at full speed |
| Maximum Speed | 1–3 m/s | Affects cycle time |
| Operating Temperature | -10–50 °C | Outside this range, performance may degrade |
| Protection Class | IP54–IP65 | IP65 for dusty or wet environmentsIEC 60529 |
| Supply Voltage | 220–380 V AC | Three-phase for industrial useIEC 60038 |
| Power Consumption | 1–5 kW | Depends on payload and speed |
| Weight | 50–300 kg | Affects mounting and floor loading |
| Mounting Type | Floor, wall, ceiling | Flexible mounting options |
| Control Interface | EtherCAT, PROFINET, Modbus TCP | Compatibility with PLC systemsIEC 61158 |
Ranges are indicative industry figures for RFQ preparation, not a supplier commitment. Confirm every value and standard with the legal manufacturer before ordering.
| pressure: | N/A (mechanical positioning system) |
| other spec: | Payload capacity: 1-50 kg, Repeatability: ±0.02-0.5 mm, Reach: 0.5-3.0 m, IP rating: IP54-IP67 |
| temperature: | 0°C to 50°C (operating), -20°C to 70°C (storage) |
Indicative industry ranges for design and RFQ preparation. Confirm the exact figures and applicable standard with the manufacturer before specifying.
Quoted from the published standard.
A practical evidence checklist for RFQ preparation and supplier evaluation.
Compare the published product scope and source details, then include your specifications and quantity in an enquiry.
Manufacturer profiles associated with Robotic Manipulator Arm.
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Ask for use case, specification boundaries, supplier type, and RFQ preparation information for this product.
The reach, defined as the maximum horizontal distance from the robot base to the end-effector, ranges from 600 to 1500 mm. This is a reference range; the exact reach depends on the specific model and configuration. Always verify with the manufacturer.
The arm typically has 4 to 6 degrees of freedom, meaning it has 4 to 6 independent axes of motion. This allows for flexible positioning and orientation of the end-effector. The exact number depends on the model.
The repeatability, as per ISO 9283, is ±0.05 to ±0.1 mm. This indicates the positional accuracy when returning to a taught point. It is a reference range; the actual value for a specific model should be confirmed with the manufacturer.
The arm supports EtherCAT, PROFINET, and Modbus TCP, which are common industrial Ethernet protocols. These interfaces ensure compatibility with PLC systems. The specific interface options may vary by model, so verify with the supplier.
This component is essential for the following industrial systems and equipment:
Commonly used trade names and technical identifiers for Robotic Manipulator Arm.
Editorial classification, named public sources where available, and source-reviewed manufacturer records.
Compare manufacturer profiles with relevant product and process capability.