Rotor balancing · Balance grade and permissible unbalance, two-plane split, correction by milling or drilling, automatic stations
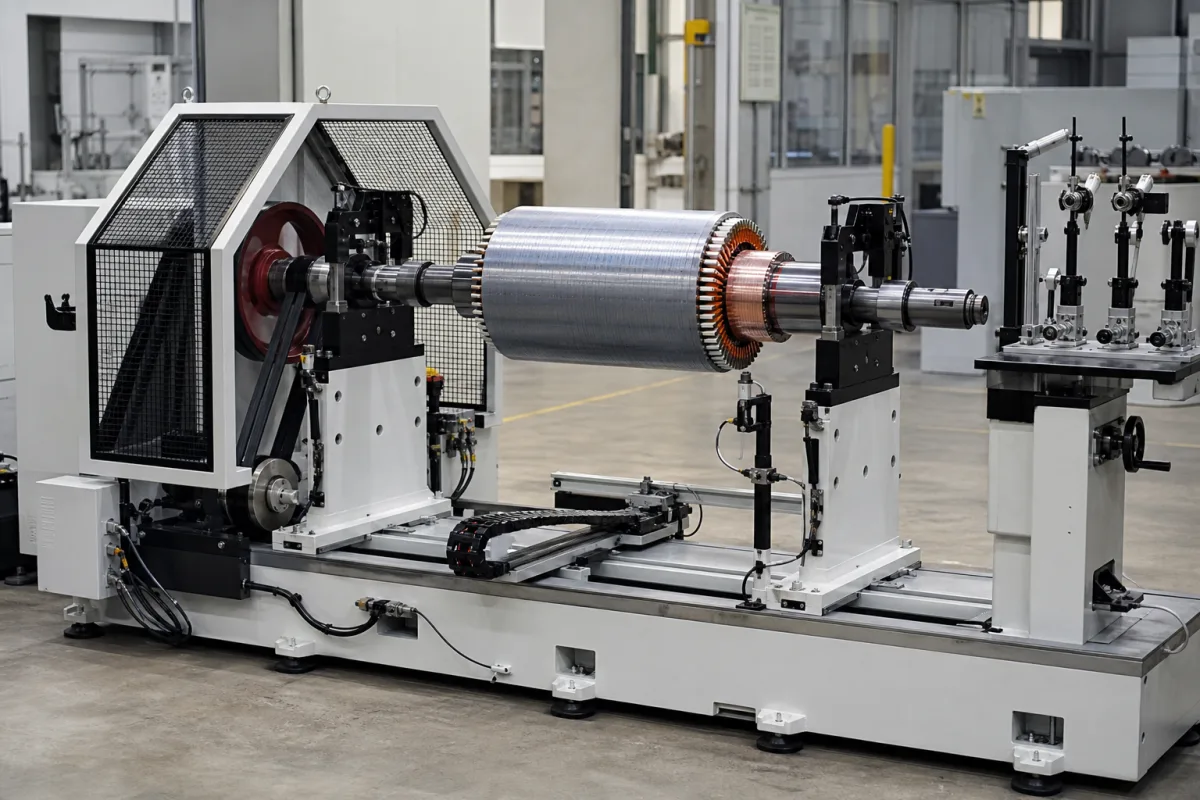
An electric motor rotor balancing machine spins a motor rotor or armature on its journals, measures the unbalance in one or two correction planes, and shows or makes the correction, either manually with weights or automatically by drilling or milling material away. Ask three things first: what residual unbalance tolerance your rotor must meet at its service speed, how the tolerance is split between the correction planes, and how the machine measures, corrects and re-checks the rotor at your production rate.
Horizontal balancing machines for motor rotors and armatures, from universal manual machines to automatic multi-station machines with drilling or milling correction. Field balancing instruments, flexible-rotor high-speed balancing and the rotors themselves are outside this page.
CNFX editorial research · Sources checked October 18, 2026 · 4 sources
Set the balance tolerance from grade, speed and mass
ISO 1940-1:2003 (BS ISO 1940-1), for rotors in a constant (rigid) state, specifies balance tolerances, the necessary number of correction planes and methods of verifying residual unbalance, and recommends balance quality requirements by machinery type and maximum service speed. It states acceptance criteria between the maker and user of rotating machines and does not cover flexible rotors. [1]
Sensemore, a vibration monitoring company, explains that ISO 21940-11 superseded ISO 1940-1 and that a balance quality grade is the permissible specific unbalance multiplied by the angular velocity at service speed, in mm/s; because speed is in the product, the permissible eccentricity halves each time the service speed doubles. For two correction planes roughly symmetric about the centre of gravity, half the permissible unbalance goes to each plane; otherwise the standard allocates and bounds the split. It notes that a machine builder's stated tolerance governs over the grade. [2]
Editorial calculation: assume a rigid rotor of 5 kg, service speed 3,000 rpm and an agreed grade G 2.5; this example does not assign that grade to a motor. Angular speed is 2π × 3,000/60 ≈ 314 rad/s, giving permissible specific unbalance about 8.0 µm and total unbalance about 40 g·mm. Only if equal plane allocation is appropriate for the symmetric rotor/plane geometry, each plane gets about 20 g·mm. At an assumed usable correction radius of 30 mm, that corresponds to about 0.66 g in each plane. Verify the actual plane allocation and correction constraints for the rotor drawing. [2]
Give the supplier the rotor drawings (mass, length, journal and bearing positions, diameters), service speed, required balance grade or tolerance, correction planes and radii, correction method (weights, drilling, milling), production rate, rotor variants and changeover, and data interfaces.
02
Plan correction and stations for your volume
Schenck's armature balancing page notes that rising electric motor speeds raise the demands on armature balancing quality, and offers four-, five- and six-station automatic machines that correct by milling or drilling adapted to rotor geometry. Its KBTU series corrects by profile, polar or slot milling or drilling in one or two planes, with a transfer station, measuring station, correction stations, a separate measuring station for an audit check, internal lifting and turning transport, control cabinet and protective device. [3]
Its five-station CIVO is described as suited to up to about 2 million small armatures a year, up to 500 g (optionally 3 kg). Interfaces for line control and MES data are offered. [3]
Editorial production arithmetic: assume a target of 2,000,000 accepted armatures over exactly 6,000 available production hours, no downtime, no scrap and one completed part at each output interval. Required average output is approximately 333 per hour, or a 10.8 s output interval (about 11 s). The annual-volume figure alone does not prove a CIVO cycle time: station overlap, loading, correction loops, audit checks, changeovers and availability must be evaluated for the actual rotor. [3]
03
Check residual-unbalance measurement and indexing assumptions
US patent 10,101,235 B2 describes an indexing method to separate a fixed machine/fixture contribution from rotor unbalance. It references evaluation terminology from ISO 2953:1999 and GB/T 4201-2006. These references and the inventor’s critique do not establish the current standard requirements or verify a particular machine’s accuracy. Agree the applicable evaluation standard and acceptance procedure separately. [4]
The patent describes measuring with a consistent angle reference, indexing the rotor 180° relative to the drive and measuring again. Under its vector model, a fixed machine contribution stays unchanged while the rotor contribution reverses; half the sum gives the fixed contribution and half the difference gives the rotor contribution. This separation depends on stable mounting and repeatable measurements. A patent disclosure is not a calibration certificate or an uncertainty evaluation. [4]
Editorial vector example: assume one plane, readings exactly collinear at 30 g·mm and 10 g·mm in the same reference direction, a perfect 180° index, unchanged fixture contribution and no noise, drift or reseating error. Half-sum is (30 + 10)/2 = 20 g·mm; half-difference is (30 − 10)/2 = 10 g·mm. For readings at other angles, calculate vector components rather than subtracting magnitudes. This hypothetical separation does not demonstrate compliance with any rotor tolerance. [4]
Editorial note: ask the supplier to show Umar and Urr test results at acceptance, which proving rotor they use, and whether the machine software supports an index (180°) compensation run for your fixtures and adaptors.
Check
What it shows
Source
Minimum Achievable Residual Unbalance (Umar)
A term referenced by the patent’s cited evaluation documents; agree the applicable standard and test conditions.
Nide lists a rotor balancing-machine category among motor-production equipment. Jianping lists motor-industry balancers alongside universal and automatic machines. Define the rotor family, drive, supports and supplied correction capability on the quotation; a product-category listing is not evidence of the tolerance or cycle time for the ordered rotor.
05
Rotor supports, measuring system and correction stations
Rotor envelope, measuring capability and production utilities
Field
What it means and published values
Ask the supplier for
Maximum rotor weight (kg)
Up to 500 g (option 3 kg) on one automatic model. [3]
Weight range.
Balancing speed range (RPM)
Measuring speed.
Range.
Unbalance reduction ratio (%)
Share of initial unbalance removed per run.
Guaranteed ratio.
Rotor diameter range (mm)
Fits your rotors.
Range.
Measurement accuracy (g·mm/kg)
Specify residual-unbalance capability, repeatability and test uncertainty against the agreed tolerance. A balance grade is not a machine-accuracy specification.
Minimum achievable residual unbalance.
Power consumption (kW)
Utility.
Value.
Supply voltage (V AC)
Site supply.
Voltage.
Operating temperature (°C)
Shop ambient.
Range.
Relative humidity (%)
Shop ambient.
Range.
Ingress protection
Enclosure.
IP code.
Machine weight (kg)
Foundation.
Weight.
Footprint (L×W×H)
Layout.
Drawing.
07
Send the rotor, tolerance and volume data together
Paste it into your enquiry below or into an email to a maker, then replace every bracket.
Rotor: [mass; length; journals; diameters]
Tolerance: [grade or g·mm; service speed; planes]
Correction: [weights; drilling; milling; radii]
Volume: [rotors per year; cycle time; variants]
Checks: [audit re-measure; data to MES]
Supply: [voltage; air; floor space]
2 companies list this product among what they make. Company figures are quoted from each
company's own website; every card states where the relationship came from.
Ningbo NIDE Tech Co., Ltd.
TBC
Lists rotor balancing machines among motor rotor production equipment.
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Share this page
Compiled and source-reviewed by the CNFX editorial team.
Each manufacturer above links to the page on that company's own website where the product is listed, with the date we checked it. How we source and review
· Page last updated 13 October 2026
Buyer questions
What does balance grade G 2.5 mean?
Balance grade relates permissible specific unbalance to service angular speed. In an editorial example assuming G 2.5 and 3,000 rpm, the specific unbalance is about 8 µm (8 g·mm/kg); use the grade and conditions actually specified for the rotor. [2]
How is the tolerance split between two planes?
Equal halves apply only when the relevant symmetric rotor and correction-plane assumptions hold. Asymmetric plane locations require the appropriate allocation and checks. [2]
How do automatic machines correct armature unbalance?
Schenck's machines mill or drill material in one or two planes and re-measure at an audit station. [3]
What does a 180° rotor indexing test try to separate?
The cited patent models a fixed machine/fixture contribution and a rotor contribution that reverses after indexing. Vector separation assumes stable geometry, angle reference and repeatability; it does not account for every possible source of disagreement between machines. [4]
Sources and what still needs a direct check
Sources checked 2026-10-18. BSI summarises ISO 1940-1 (since superseded by ISO 21940-11), whose grade table was not read for this page; Sensemore explains the grade arithmetic; Schenck describes its own armature balancers; US patent 10,101,235 B2 describes how machine and rotor unbalance are separated.