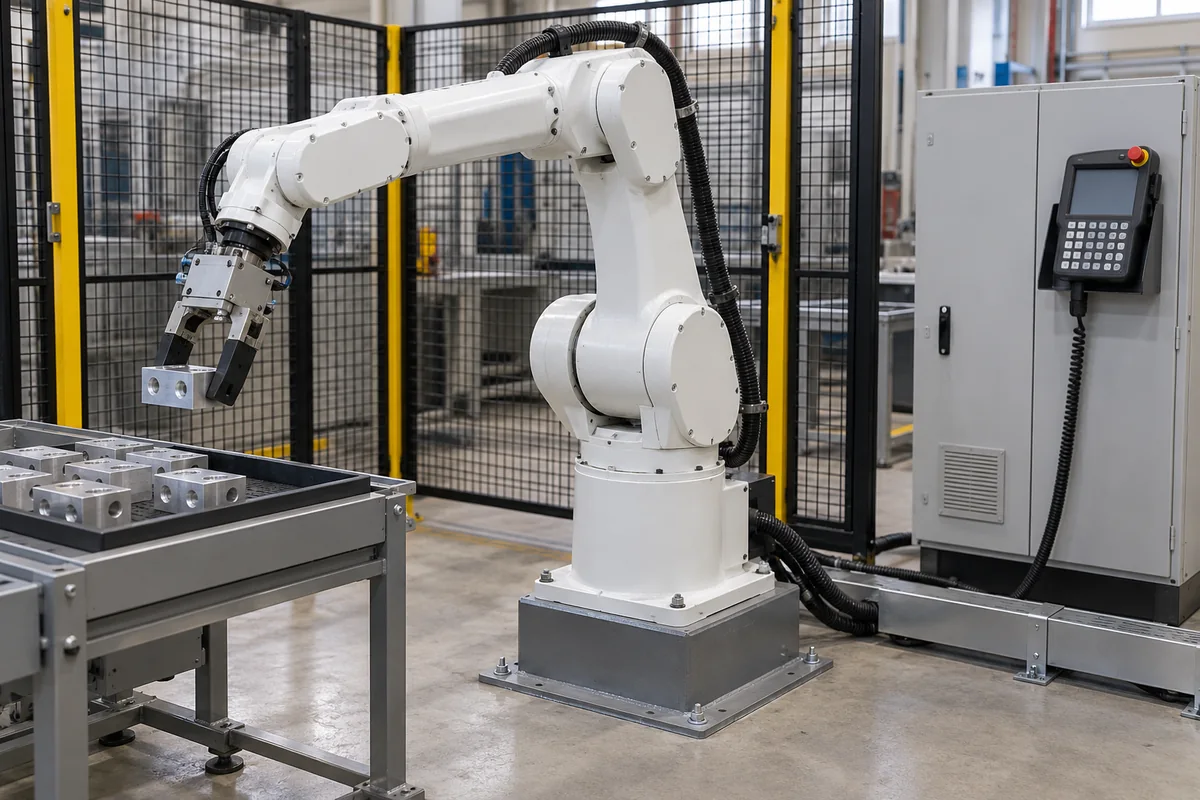
Industrial robot arms · Articulated, SCARA, Cartesian and parallel robots, specified by axes, payload, reach and repeatability — for example a six-axis floor robot carrying 150–235 kg at 2,650–3,200 mm with ±0.04–0.06 mm repeatability
An industrial robot arm is a programmable manipulator that moves a tool or part through space; with an end-effector, controller, sensors and safeguarding it becomes a robot system for handling, welding, machine tending, palletizing and other tasks. Ask three things first: what payload, reach and repeatability the task needs, which robot structure and how many axes suit the motion, and how the cell will be programmed, tooled and safeguarded.
Industrial robot manipulators for general automation — articulated (six-axis and similar), SCARA, Cartesian or gantry and parallel robots — supplied as robot arms with controllers for handling, welding, palletizing, machine tending and similar tasks. Robots selected for assembly (see assembly robot), wafer-handling robots (see transfer robot), robot controllers (see robot controller), teach pendants, end-effectors and grippers (see robot end effectors), and complete welding or palletizing cells sold as lines are outside this page except where compared.
CNFX editorial research · Sources checked October 11, 2026 · 4 sources
OSHA's Technical Manual describes an industrial robot system as the robot together with its end-effector, control system, power sources, sensors and sequencing or monitoring communications. The manipulator is a structural frame with linkages, joints, guides, linear or rotary actuators, valves and sensors; robot drives are electrically powered in the usual case, with pneumatic power used for end-effectors in some systems; and robots are programmed with a teach pendant in manual mode. [1]
The manual names four structures. Articulated robots have at least three rotary joints and can reach any point in their working space, much like a worker's arm, for light to heavy loads. SCARA robots have two parallel rotary joints, compliant in the XY plane and rigid in Z, and are used in assembly. Cartesian (linear, XYZ or gantry) robots move in two or three linear axes with a rigid structure for heavy loads, pick and place, loading, material handling and molding. Parallel robots join chains, rods or cables to a single tool point for very high-speed pick and place. It also separates collaborative applications, designed for direct interaction with workers, from non-collaborative ones. [1]
Reseller listings show the range on offer, from an 18 kg collaborative arm with 1,100 mm span to an ABB IRB 6700 at 300 kg and a 7-axis KUKA LBR iiwa at 7 kg. [3]
Give the supplier the task and cycle time, part or tool mass and centre of gravity, reach and working envelope, repeatability, number of axes and mounting, environment (temperature, dust, coolant, washdown, explosion risk), controller and communication interfaces, end-effector and dress pack, safeguarding concept and standard, and programming and training support.
02
Size payload, reach, repeatability and axis motion
RobotWorx's datasheet for the ABB IRB 6700-235 lists a six-axis articulated, floor-mounted robot with 235 kg payload, 2,650 mm horizontal reach, ±0.04 mm repeatability and a 1,250 kg robot mass; axis ranges of ±170° (axis 1), +85° to −65° (axis 2), +70° to −180° (axis 3), ±300° (axis 4), ±130° (axis 5) and ±360° (axis 6); and axis speeds of 100, 90, 90, 170, 120 and 190 °/s. Variants are listed at 205 kg / 2,800 mm / 0.06 mm, 175 kg / 3,050 mm / 0.04 mm and 150 kg / 3,200 mm / 0.05 mm, with the IRC5 controller. [2]
OSHA's manual states that the safety standard for robots and robot systems is ANSI/RIA R15.06-2012, Parts 1 and 2, requiring safe operating and maintenance information for the robot and the application, and integrators to carry out hazard analyses and risk assessments for each application; it describes contact, crushing and trapping hazards and the need for teach pendants with enabling devices and safeguarding active in automatic mode. [1]
Editorial calculation: across the four IRB 6700 variants, each step to longer reach lowers payload — from 235 kg at 2,650 mm to 150 kg at 3,200 mm, 85 kg less for 550 mm more reach; the robot weighs about 5.3 times its rated payload in the 235 kg version. [2]
03
Check where industrial robot arms are installed and who supplies them
The International Federation of Robotics (IFR) counts industrial robot installations each year. Its World Robotics 2025 release reports 542,000 industrial robots installed worldwide in 2024, more than double the number ten years earlier and the fourth straight year above 500,000 units, with 4,664,000 units in operational use, up 9% on the previous year. Asia took 74% of new installations, Europe 16% and the Americas 9%. [4]
China installed 295,000 units in 2024, 54% of the world total and its highest annual figure on record, and its operational stock passed 2 million. The IFR states that Chinese manufacturers outsold foreign suppliers in China for the first time, with a domestic market share of 57%, up from about 28% over the past decade. The United States installed 34,200 units (down 9%), and the IFR notes that it imports its robots from Japan and Europe and has few domestic suppliers. Germany installed 26,982 units, 32% of the European total. [4]
Editorial note: these market figures do not rank individual robot makers, so ask any supplier, including resellers such as those listed on this page, to name the original manufacturer, model and country of manufacture, and to state who supplies spare parts and service locally. [4][3]
Editorial calculation: 4,664,000 units in operation against 542,000 installed in one year means the 2024 installations equal about 12% of the operational stock. [4]
The companies below list industrial robot arms on their own websites. A listing shows what a company offers; confirm the legal seller, the robot's original manufacturer and the configuration for your order.
Ask any supplier for the original manufacturer and model, new or reconditioned status, payload and load diagram, reach and envelope drawing, repeatability, axis ranges and speeds, protection class, mounting options, controller and software, dress pack, safety functions and certification, warranty and local service.
05
Trace what each part does
This is a functional reference built from the sources cited; it is not one maker's specification.
Part
Role
Fix in the order
Manipulator (arm)
Frame, joints and actuators that move the tool. [1]
Fill the specification fields with values for your order
A robot arm quotation needs values for your task and cell. The table explains each field, gives published values where a reviewed source states them, and says what to obtain from the supplier.
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Share this page
Compiled and source-reviewed by the CNFX editorial team.
Published product pages show what a company offers, not tested performance. Confirm the legal seller, factory and scope for your order. How we source and review
· Page last updated 13 October 2026
What does repeatability mean on a robot datasheet?
Datasheets quote it in ± mm; one six-axis floor robot lists ±0.04 mm. [2]
Which safety standard covers industrial robots in the US?
OSHA cites ANSI/RIA R15.06-2012, Parts 1 and 2. [1]
How many industrial robots are installed each year?
The IFR reports 542,000 industrial robots installed worldwide in 2024 and 4,664,000 in operational use; China installed 295,000, 54% of the total. [4]
Sources and what still needs a direct check
Sources checked 2026-10-11. OSHA publishes the Technical Manual chapter on industrial robots; the International Federation of Robotics publishes annual installation statistics; RobotWorx integrates and resells robots; Youngyou resells robot arms.