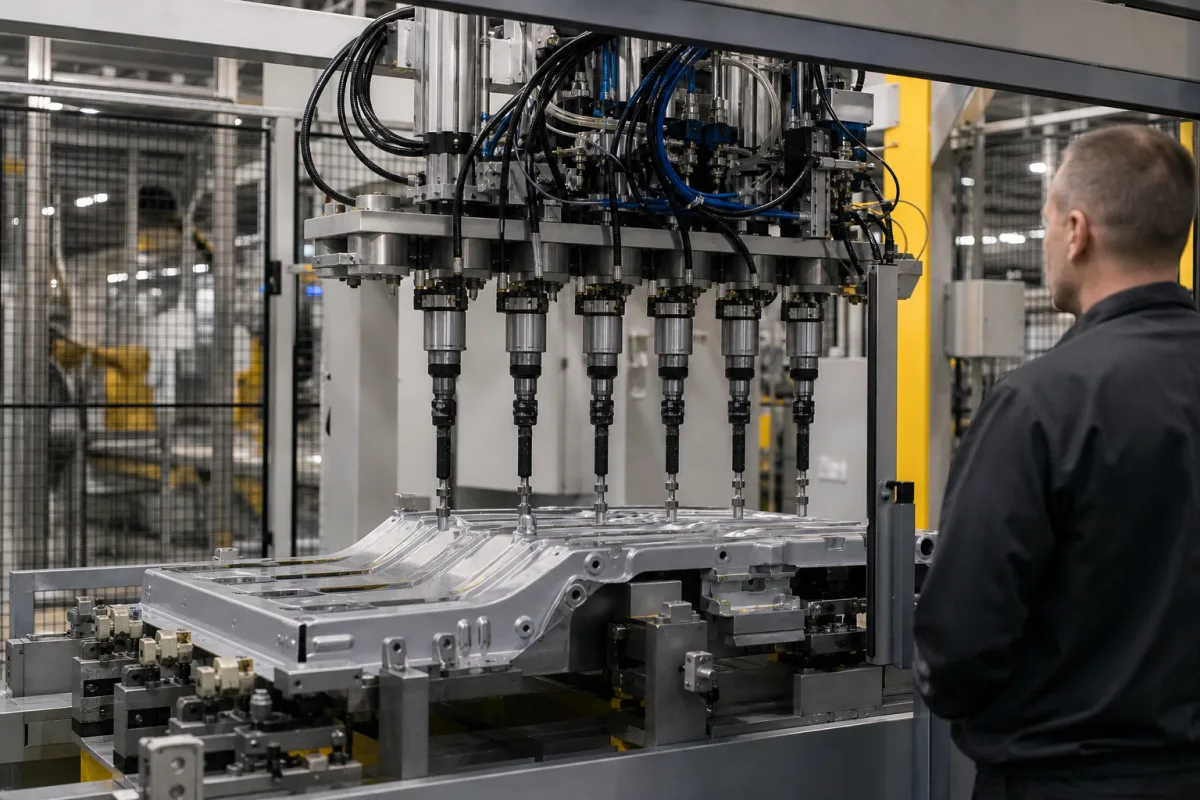
Multi-spindle tightening head for chassis bolt patterns: how close the spindles can sit, how far each one floats, and tightening a bolt group in stages
Chassis and subframe assembly · a row or circle of nutrunner spindles on one carrier that runs down and tightens a whole bolt group in one stroke
When a part has six, eight or ten bolts that all have to be tight before it moves on, tightening them one after another with a single spindle eats the cycle. A multi-spindle head mounts a nutrunner spindle over every bolt position on one carrier, lowers onto the part, and runs all of them down together. What limits it is geometry and the joint: how close two spindles can be placed side by side, how much axial travel each spindle has to follow its bolt head down, which torque size each position needs, and in what steps the whole group is brought to final torque so that one bolt does not unload its neighbours.
Multi-spindle tightening heads and stations for automotive chassis, subframe, battery-tray and wheel assemblies: the carrier plate with its fixed or adjustable spindle positions, straight, offset and angle-head spindles with their axial compensation, the run-down and staged tightening of a bolt group, and robot-carried heads for wheel bolts and nuts. Torque, angle and yield tightening strategies and the transducerised spindle and controller are covered on the Fixtured electric nutrunner torque control system for vehicle and powertrain assembly page; blow-fed screwdriving heads on the Fastener installation module page; assembly robots on the Assembly robot page and compliant insertion on the Robotic assembly arm for compliant insertion page. Frame location and tightening of rubber-bushed suspension joints are covered on the Ladder-frame chassis dressing station page, axle and drive module rigging on the Chassis rigging and marriage line page, and riveting and screwing of mixed-material bodies on the Mixed-material body-in-white joining line page.
CNFX editorial research · Sources checked October 13, 2026 · 3 sources
How close the spindles can sit: torque size, offset output drives and the minimum circle for two to six spindles
The bolt pattern sets the spindle layout, and the spindle's torque size sets how tightly it can be packed. Bosch Rexroth's tightening-systems catalogue (2018 edition, its pages marked as blocked for new applications) shows the trade-off in one product family: spindles from 0.6 to 1,000 Nm built from straight, offset or angle-head output drives, with offset drives offered for tight hole patterns. [1]
The same catalogue lists axial spring travel ("range of spring") of 20 mm on size 2 spindle bearings and offset drives, 25 or 50 mm on size 3, 50 mm on size 4 and 80 mm on size 5 and on size 4 offset drives with integrated transducer, with spring forces from 14–38 N up to 40–155 N. [1] That travel is what lets each spindle follow its own bolt as it runs down while the carrier stays still, so it has to cover the bolt's run-down length plus any height difference between bolt positions on the part. The catalogue also requires an angle head always to be run with an axial compensator such as a spindle bearing, and offers output drives for higher transverse forces, for example for wheel nutrunners, on request. [1]
Editorial calculation from the table: two size-3 offset spindles need at least 29 mm between centres, about 1.3 times the 23 mm of two size-2 spindles, while the 1.7–53 Nm size-3 range reaches over five times the 10 Nm top of size 2. A bolt pattern tighter than the minimum circle for the torque needed cannot be done with one stroke of that head; it needs a second head position or a different output drive.
Rexroth spindle size and output drive
Working range
Max. output speed
Min. circle diameter for 2 / 3 / 4 / 5 / 6 spindles side by side
Send the bolt pattern with coordinates and the smallest centre distance, the target torque and angle for each position, the run-down length and the height differences between bolt positions, and the access space around each bolt for sockets.
02
Tightening a bolt group in stages: why the head should stop at an intermediate torque before final
Running every spindle straight to final torque does not leave every bolt with the same clamp load, because tightening one bolt compresses the joint under its neighbours. Lin's 2026 finite-element study of a ten-bolt aerospace curvic coupling, with a flat shaft disk of the same size as reference, quantifies how much the order and the number of steps matter.
The study compared sequential, single-axis crisscross and dual-axis crisscross orders, and one-, two- and three-step loading paths in which every bolt is first brought to a fraction of the target preload and then completed. The dual-axis crisscross order reduced the standard deviation of residual preload by 12.06 % compared with single-axis crisscross, and the 40 %–80 %–100 % three-step dual-axis path gave the smallest scatter: compared with single-step tightening it cut the variation range of the normalised residual preload by 81.6 % and the standard deviation by 72.6 %, with smaller further gains of 16.59 % and 17.17 % over the best two-step path (80 %–100 %). [2] On the flat shaft disk, the 40 %–80 %–100 % path left an average residual preload of 49.95 kN with a minimum of 49.90 kN. [2]
The author limits the findings to idealised geometry, prescribed preload and static loading, and notes that the toothed curvic interface amplifies scatter compared with a flat joint, so the figures are not a chassis specification. [2] The mechanism it identifies is that each later loading step redistributes the preload left by the step before. [2] Editorial note: a multi-spindle head that holds all spindles at a shared intermediate step before final applies that staging to the whole group in one stroke; whether it matches a crisscross result on a given chassis joint has to be shown by measuring clamp load.
Ask the head supplier whether all spindles can hold at one intermediate torque or angle step before final, whether a spindle that faults can be re-run without loosening the others, and how each bolt's result is recorded.
03
Robot-carried multi-spindle heads for wheel bolts: one stroke per wheel and a 43-second takt
Wheel fitting in final assembly is one place where such heads are carried by robots. Atlas Copco describes its Automated Wheel Multiple (AWM) as a robot-carried multi-spindle system that tightens all wheel bolts of a wheel at once, built on its fixtured QST nutrunners, with a modular design that adapts to wheel sizes, bolt patterns and variants. [3]
According to Atlas Copco, the head handles both wheel bolts and nuts on studs, including M14 and M16 hex bolts on the same line with a multi-socket changer; it is offered for stop-and-go lines with 3D vision guidance and for moving lines with a 4D dynamic guidance system; and the shortest takt in its installed base is 43 s with four AWM units and robots. [3] Editorial calculation: with four heads, each wheel position has the full 43 s for approach, run-down, tightening and retreat, against about 10.75 s per wheel if one head did all four in that takt.
A wheel head is also where the transverse force on the spindle output matters, which is why the Rexroth catalogue singles out output drives for higher transverse forces for wheel nutrunners. [1]
For wheel or hub heads, state the bolt or nut sizes and patterns across all variants, stop-and-go or moving line, the takt per vehicle, and how the head locates on the wheel.
04
What to send with a multi-spindle head enquiry
Paste it into your enquiry below or into an email to a maker, then replace every bracket.
Part: [chassis, subframe, battery tray or wheel; material; fixture]
Bolt pattern: [number of bolts; coordinates; smallest centre distance; height differences]
Joint: [bolt sizes; target torque and angle per position; run-down length]
Sequence: [intermediate step; final step; re-run of a failed spindle]
Carrier: [fixed station, slide or robot; payload limit]
Cycle: [takt; stop-and-go or moving line]
Data: [results per bolt; traceability required]
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Share this page
Compiled and source-reviewed by the CNFX editorial team.
Each manufacturer above links to the page on that company's own website where the product is listed, with the date we checked it. How we source and review
· Page last updated 13 October 2026
Buyer questions
How close can two tightening spindles be placed?
It depends on the torque size. In Bosch Rexroth's catalogue two size-2 offset spindles (0.6–10 Nm) need a 23 mm minimum circle and two size-3 offset spindles (1.7–53 Nm) 29 mm; six spindles need 52 and 58 mm. [1]
Why does a multi-spindle head need spring travel?
Each spindle has to follow its own bolt down while the carrier stays still; Rexroth lists 20 mm of axial spring travel on its smallest spindles and up to 80 mm on its largest. [1]
Does tightening in stages improve a bolt group?
In Lin's ten-bolt study, a 40 %–80 %–100 % three-step crisscross path cut the standard deviation of residual preload by 72.6 % compared with single-step tightening. [2]
How fast can a robot fit wheels with multi-spindle heads?
Atlas Copco gives 43 s as the shortest takt in its installed base, using four AWM heads and robots. [3]
Sources and what still needs a direct check
Sources checked 2026-10-13. Spindle sizes, spacing and spring travel come from Bosch Rexroth's tightening-systems catalogue; bolt-group sequence and staging from a 2026 finite-element study in PLOS ONE; robot-carried wheel heads from Atlas Copco's AWM product page.