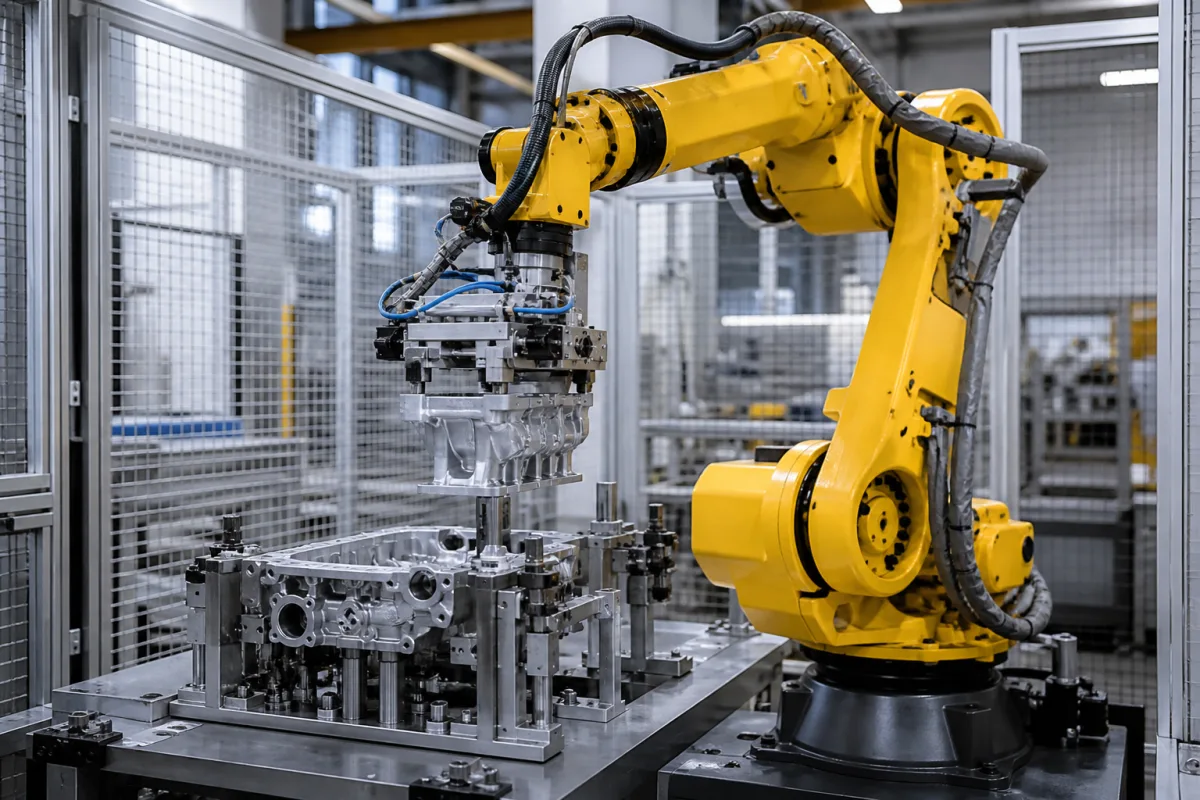
Robotic assembly arm for compliant insertion: the wrist force sensor or remote-centre compensator, the search routine, and how insertion success is measured
Robot arms set up to mate parts that fit with clearance · wrist force/torque sensors of 32–130 N, passive remote-centre compensators, impedance-controlled spiral and quasi-random searches, and NIST task boards that score pegs, gears, connectors and nuts
An assembly arm that only moves to taught points will jam a peg, shaft or locating pin as soon as the hole is off by more than the clearance. The arms used for insertion add compliance somewhere in the chain: a passive remote-centre compensator between wrist and gripper, a six-axis force/torque sensor that lets the controller feel contact, or an impedance-controlled arm that yields along the insertion axis while it searches for the hole. Specifying one means choosing that compliance, choosing how the robot searches when the part does not drop in, and agreeing how insertion time and success will be measured before the cell is accepted.
Robot arms equipped and programmed for insertion assembly: peg-in-hole and pin-in-bore mating, gear meshing, connector insertion and nut threading, with wrist force/torque sensors, passive compliance devices (remote-centre, lateral and universal compensators), impedance or force control, search routines, and the NIST task-board and peg-in-hole test methods used to measure completion time and probability of success. Assembly robots as a family (six-axis, SCARA, delta and collaborative), their payload and reach sizing and guarding are covered on the Assembly robot page; the six-axis arm as a mechanical unit on the Robotic manipulator page; machine-tool loading on the Robotic Arm/Gripper page; press tending on the Industrial robot arm for press tending page; CMM loading on the Robotic part handler for a coordinate measuring machine page; spot welding on the Articulated spot-welding robots page; and servo-press seating of motors on the Vibration motor insertion unit page.
CNFX editorial research · Sources checked October 13, 2026 · 5 sources
Wrist force/torque sensor or remote-centre compensator between flange and gripper
ATI, which makes both, describes the passive route as a remote-centre compensator (RCC) that projects a centre of compliance forward of the device on three or more elastomer shear pads, stiff axially and compliant laterally, so that when the contact point is near that centre the part corrects lateral and rotational misalignment itself, reducing contact force and preventing galling and jamming. [5] Its selection steps start from the worst-case misalignment and the total clearance, then pick a model whose centre of compliance lies within 30 % of the distance L, and finally check load capacity and the maximum insertion force. [5]
All five pads are rated for −29 to 82 °C. [5] Editorial calculation: HCL-11A is about 1,240 times stiffer axially than laterally (24,889 / 20), HCL-13A about 244 times; that ratio is what lets the pad push the part home while letting it slide sideways into the hole.
The active route measures contact instead. ATI's Gamma six-axis sensor, which it lists for robotic assembly and real-time force control, comes in metric calibrations of 32, 65 and 130 N in X and Y with 100, 200 and 400 N in Z and 2.5, 5 and 10 N·m of torque; the 65 N version resolves 1/80 N in X and Y (typ.), quoted after dropping four counts of noise. [4] It weighs 0.255 kg at 75.4 mm diameter and 33.3 mm high with standard interface plates, tolerates single-axis overloads of ±1,200 N in X and Y and ±4,100 N in Z, and has resonant frequencies of 1,400 Hz (Fx, Fy, Tz) and 2,000 Hz (Fz, Tx, Ty). [4] Editorial calculation: 1,200 N is about 18 times the 65 N rated range and 37 times the 32 N range.
Ask for the clearance and chamfer of the mating parts, the worst-case position error of robot, fixture and part, the insertion force allowed, and whether compliance is passive (RCC model and pad), sensed (F/T range and resolution) or in the arm's own control.
02
Spiral, random or quasi-random search at 1 and 2 mm position error: completion time and probability of success
NIST built a peg-in-hole test to compare insertion strategies: pegs and holes with a dimensionless clearance c = (D − d)/D of 0.02, holes about 35 cm apart, and the hole position offset before each of 60 attempts by Gaussian errors of 1 mm and 2 mm standard deviation. [1] One system was a 7-degree-of-freedom arm in Cartesian impedance control with a pneumatic parallel gripper, searching within a radius of four standard deviations (4 mm and 8 mm) with the Z stiffness reduced; the spiral pitch was set to the insertion clearance. [1]
Completion time here excludes picking and transporting the peg, so it reflects the insertion strategy alone; the Boothroyd–Dewhurst tables cited by the authors put a human at about 2.5 s for the same insertion. [1] The 95.2 % success figure is a statistical bound at 95 % confidence for a system with no failures in 60 attempts, and the authors note that the hand would have had to fail at least five times for its success rate to differ significantly at that sample size. [1] Editorial calculation: with c = 0.02, a 10 mm hole (an assumed size) leaves a peg 0.2 mm smaller, against position errors of 1 or 2 mm standard deviation, five to ten times the gap.
For acceptance of a whole cell, NIST's assembly task boards turn the same idea into a scored test: Task Board 1 combines peg insertion (rods of 4, 8, 12 and 16 mm and matching bars), gear meshing, BNC, waterproof, D-sub, USB and RJ45 connector insertion and M4 to M16 nut threading, with the board and kit placed at random and no human intervention once the robot starts. [2][3] Disassembly scores out of 60 points and assembly out of 120, and results are reported over 32 trials with mean, standard deviation and 95 % confidence interval of completion time. [2]
Agree the acceptance test before ordering: part set, clearance, applied position error, number of trials, and whether completion time includes pick and transport.
03
Data for an insertion assembly arm
Paste it into your enquiry below or into an email to a maker, then replace every bracket.
Parts: [peg or shaft diameter; hole diameter; chamfers; material]
Position error: [robot, fixture and part tolerances; vision or not]
Compliance: [RCC, lateral or universal compensator; or F/T sensor range and resolution; or arm impedance control]
Forces: [maximum insertion force; part mass and gripper mass]
Strategy: [search pattern; force thresholds; retry rules]
Acceptance: [test parts; trials; completion time; probability of success]
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Share this page
Compiled and source-reviewed by the CNFX editorial team.
Each manufacturer above links to the page on that company's own website where the product is listed, with the date we checked it. How we source and review
· Page last updated 13 October 2026
Buyer questions
How does a remote-centre compensator help a robot insert a peg?
Its elastomer shear pads are stiff axially and compliant laterally and project a centre of compliance ahead of the device, so a part contacting near that point corrects its own lateral and angular misalignment instead of jamming. [5]
What force range does a wrist sensor for assembly need?
ATI's Gamma sensor, listed for robotic assembly, comes in 32, 65 or 130 N lateral and 100, 200 or 400 N axial ranges, with overload limits of ±1,200 N lateral and ±4,100 N axial. [4]
Which search routine inserts fastest?
In NIST's peg-in-hole test at 2 % clearance, an impedance-controlled arm with a quasi-random search averaged 3.11 s at 1 mm position error and 8.2 s at 2 mm, against 7.19 s and 37.13 s for a spiral. [1]
How is an assembly robot's performance benchmarked?
NIST's task-board protocol scores insertions, meshing, connectors and nuts out of 120 points for assembly, with random board placement, no human intervention, and statistics over 32 trials. [2][3]
Sources and what still needs a direct check
Sources checked 2026-10-13. Three NIST documents (the peg-in-hole comparison published in IEEE Transactions on Robotics and the Task Board 1 benchmark and protocol) and two ATI Industrial Automation product sources for the Gamma force/torque sensor and RCC compliance devices.