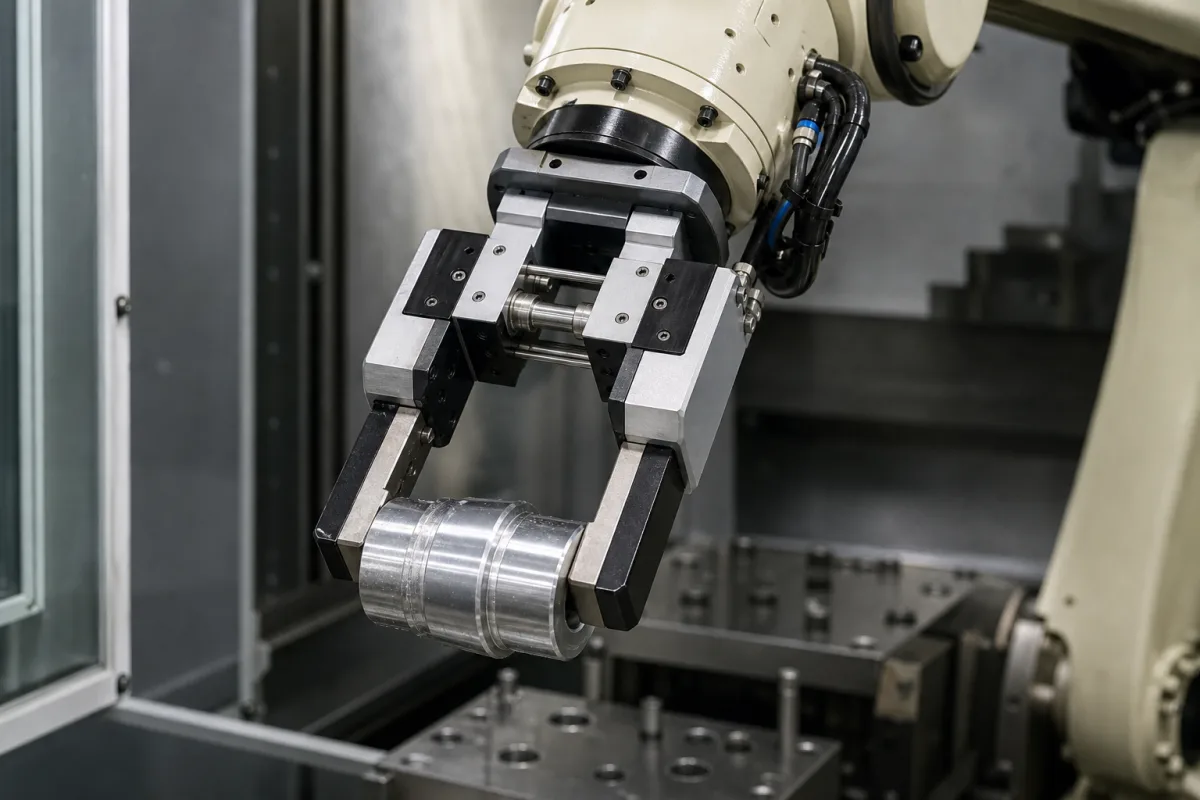
The illustrated end effector is a pneumatic two-jaw parallel gripper with long fingers, holding a turned aluminium part at a machining cell. Picking the part is the easy half; loading it into a chuck or fixture means the part must arrive within the clearance the workholding allows. That depends on the robot's and the gripper's repeatability, on whether a compensation unit gives way when the two do not line up, and on what the gripper datasheet guarantees.
Covers parallel grippers as end effectors for machine tending and part insertion: robot and gripper repeatability and how they combine, compensation units between robot and gripper, and reading a gripper datasheet for stroke, cycle time, loads and environment. Clamping force from friction and safety factor, jaw length and air-failure behaviour are on Robot Gripper (End Effector) (4660); finger design and jaw sensing on Robotic Gripper (4125); multi-cup vacuum end effectors for machine tending on Specialized End Effector (1017).
CNFX editorial research · Sources checked October 13, 2026 · 3 sources
Robot ±0.02 mm plus gripper 0.01 mm: what the part sees at the chuck
Two repeatability figures sit between the taught position and the part. FANUC gives ±0.02 mm for its M-20iD/25 handling robot (25 kg payload, 1831 mm reach); SCHUNK gives a repeat accuracy of 0.01 mm for the PGN-plus-P 100-1-P gripper, defined as the spread of the end position over 100 consecutive strokes.
On these figures the straight sum, 0.03 mm, already exceeds the ±0.025 mm radial room of an example fit with 0.05 mm diametral clearance, while the root-sum-of-squares figure, about 0.022 mm, just fits (Editorial calculation). Neither figure includes the part's own diameter tolerance, finger wear, or the part shifting in the jaws, so a tight fit needs a lead-in or a compensating element.
Repeatability describes return to a taught point; it says nothing about how far that point is from the chuck axis. Teaching the load position at the machine removes the absolute error but not the repeatability band.
0.05 mm diametral clearance = ±0.025 mm radial room
Illustrative only
The 0.05 mm fit is an editorial example; use the actual chuck, collet or fixture clearance.
02
Compensation units: letting the gripper give way in XY, Z, angle or rotation
SCHUNK places compensation units between robot and tool for connecting, assembling, inserting, loading and unloading workpieces, to prevent damage to tools or workpieces and malfunctions from imprecise tolerances.
SCHUNK's product finder sorts its range by compensation travel: in XY below 5 mm, 5 to 10 mm and above 10 mm, and in Z below 10 mm, 10 to 13 mm and above 13 mm. Against the 0.03 mm repeatability stack above, even the smallest XY band is two orders of magnitude larger (Editorial calculation), so the choice is driven by the misalignment the part and seat can have, not by the robot.
Robot-side, SCHUNK's units bolt to the robot's ISO 9409-1 flange; in a code such as ISO 9409-1-125-6-M10, 125 is the bolt-circle diameter and 6-M10 the six M10 screws.
Compensation direction
What it absorbs
XY
Lateral offset between part and seat
Z
Axial overtravel or height variation
XYZ
Lateral and axial together
Angle (W)
Tilt between part axis and seat axis
Rotational (R)
Rotation about the tool axis
WZ
Tilt with axial travel
Compensation adds length and mass between flange and part, which counts against the robot's payload and the gripper's moment limits.
03
Reading a machine-tending gripper's data: PGN-plus-P 100-1-P as an example
SCHUNK's universal gripper in its precision version shows which datasheet lines decide fitness for machine tending.
SCHUNK notes that the moments and forces are static values per base jaw that may occur simultaneously, and that the gripping force itself adds a moment on top; it also notes that the full gripping force may take a few hundred gripping cycles to appear. A newly fitted gripper should therefore not be judged on grip before that run-in.
A 10 mm stroke per jaw covers a 20 mm range of part diameter for one finger set, and open plus close takes 0.12 s of the robot cycle (Editorial calculation). IP40 is the class stated for this variant; a gripper working inside a machine tool's coolant and chip zone needs its protection class checked against that environment.
Item
PGN-plus-P 100-1-P
Stroke per jaw
10 mm
Closing / opening force
870 / 930 N at the stated finger length; 930 / 1000 N at 0 mm finger length
Closing / opening time
0.06 s / 0.06 s
Operating pressure
2.5–8 bar, nominal 6 bar; air purge 0.5–1.0 bar
Max. finger length / weight per finger
160 mm / 1.3 kg
Recommended workpiece weight
4.35 kg, calculated by SCHUNK for force-fit gripping with static friction 0.1 and safety factor 2 against slipping at g
Moments per base jaw
Mx 87 N·m, My 115 N·m, Mz 80 N·m; axial force Fz 2700 N
Protection / temperature
IP40; 5–90 °C ambient; cleanroom class ISO 14644-1 class 6
Mass / size
0.9 kg; 120 × 50 × 54.8 mm
Values are SCHUNK's for this one variant; other sizes and versions of the series differ.
04
What to give for a machine-tending gripper and compensation
Paste it into your enquiry below or into an email to a maker, then replace every bracket.
State the part's weight, diameter range and tolerance, the chuck or fixture clearance and any lead-in chamfer, the robot model and its stated repeatability, the cycle time, coolant and chips in the working area, and the robot flange. Ask for gripper repeat accuracy and how it is defined, stroke, forces and times at your pressure, moment limits, protection class and purge options, and a compensation unit with the travel in each direction your fit needs.
1 company lists this product among what they make. Company figures are quoted from each
company's own website; every card states where the relationship came from.
Nanjing Brisk Metal Technology Co., Ltd.
TBC
Nanjing Brisk sells sheet-metal grippers and modular transfer end effectors for press and transfer lines. Repeatability, compensation and protection data are not published on its pages; TBC. Location TBC.
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Compiled and source-reviewed by the CNFX editorial team.
Each manufacturer above links to the page on that company's own website where the product is listed, with the date we checked it. How we source and review
· Page last updated 13 October 2026
How accurate is a robot-and-gripper load into a chuck?
With FANUC's ±0.02 mm robot repeatability and SCHUNK's 0.01 mm gripper repeat accuracy, the straight sum is 0.03 mm and the root sum of squares about 0.022 mm (Editorial calculation), before part tolerance and slip. [3][1]
How does SCHUNK define gripper repeat accuracy?
As the spread of the end position over 100 consecutive strokes; for the PGN-plus-P 100-1-P it is 0.01 mm. [1]
What does a compensation unit do?
SCHUNK fits it between robot and tool so the end effector can give way in XY, Z, XYZ, angle, rotation or WZ when inserting or loading, preventing damage from imprecise tolerances. [2]
Why does a new gripper seem weak at first?
SCHUNK states that it may take a few hundred gripping cycles until the full gripping force in its data table is available. [1]
Sources and what still needs a direct check
Sources checked 2026-10-13. A gripper maker's product data and compensation-unit range, and a robot maker's handling-robot page.