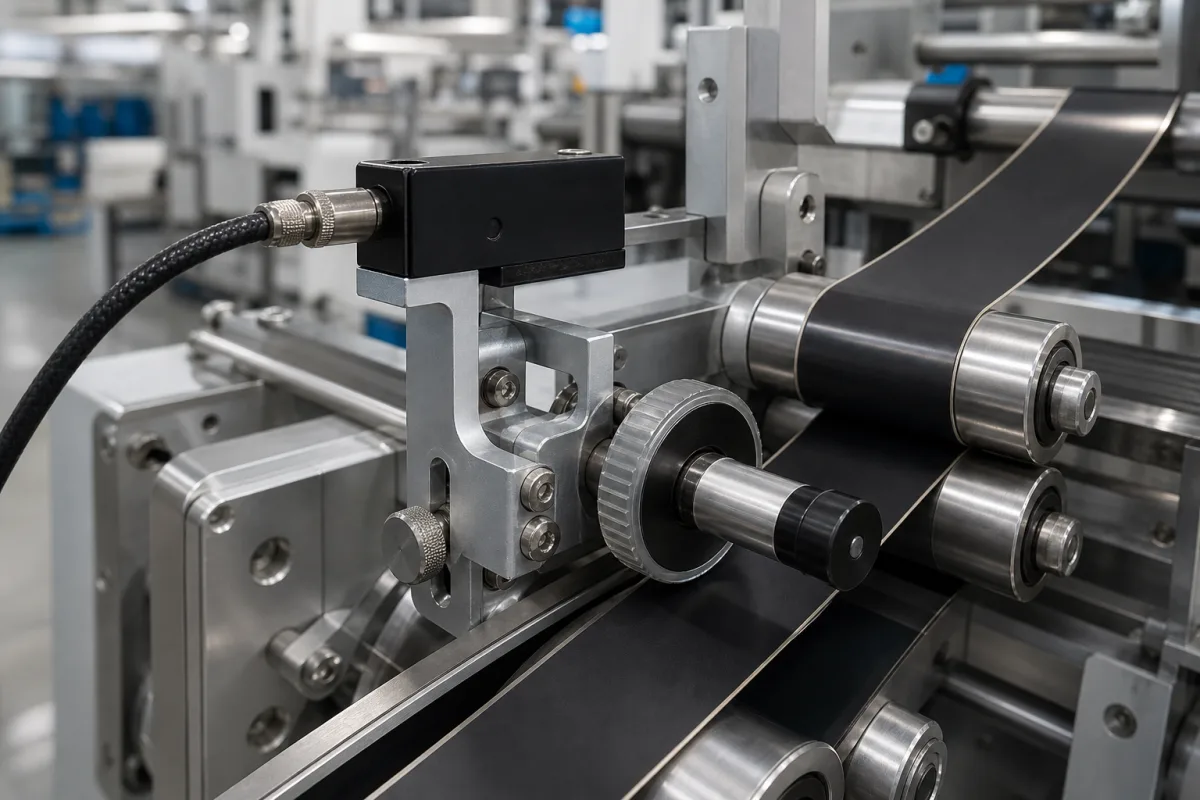
Linear position sensors · Magnetostrictive (time-of-flight) and LVDT (inductive) sensors that measure absolute, non-contact position over ±1 mm to 1,500 mm strokes, with µm-level linearity, IP67 housings and analog, SSI or fieldbus outputs
A linear position sensor reports where a moving part — a cylinder rod, a slide, an actuator or a web-handling roller — sits along its travel, as an absolute value rather than counted steps. This page covers two contactless principles: magnetostrictive sensors that time a strain pulse along a waveguide to a moving magnet, and LVDTs that read a plunger's position from two transformer windings. Ask three things first: what stroke and accuracy you need, what output your controller accepts, and what temperature, shock, pressure and sealing the installation demands.
Absolute, contactless linear position sensors for machines and automation: magnetostrictive rod, profile and rod-and-cylinder sensors with their position magnets, and LVDT (linear variable differential transformer) displacement sensors with their controllers. Incremental and absolute encoders and scales (see linear encoder and high resolution encoder), proximity switches (see proximity sensor), valve position indicators (see position indicator) and tilt sensors are outside this page.
CNFX editorial research · Sources checked October 11, 2026 · 4 sources
Temposonics describes its magnetostrictive sensors as a ferromagnetic waveguide, a position magnet attached to the moving part, a strain pulse converter and electronics: a short current pulse on the waveguide interacts with the magnet's field to release a torsional strain pulse, which travels to the converter, and the time of flight gives an absolute position. The ER version is an aluminium rod-and-cylinder design whose rod extends from the housing with the magnet protected inside, mountable in any orientation, for 50–1,500 mm strokes. [1]
A peer-reviewed study from Shanghai Jiao Tong University (Zhang et al., Sensors 2011) explains the same principle from the waveguide side: torsional waves travel away from the position magnet in both directions; a coil at one end receives the wave and a damper at the other end absorbs it so it does not reflect back. Because the sensor relies on high-speed time measurement, electromagnetic interference causes random errors that calibration cannot remove. Building two 300 mm sensors, the authors found that a differential two-waveguide structure improved accuracy to ±0.1 mm against ±0.2 mm for the traditional single-waveguide structure, and reduced temperature drift in tests from 20 to 60 °C in 5 °C steps held for 15 min each. For the Ni-Span-C waveguide wire they give thermal expansion of 5 ppm/°C, a propagation-velocity change of 3 ppm/°C and a magnetostrictive constant of 30 ppm. [3]
Editorial calculation: if a 3 ppm/°C velocity change were left uncompensated over the 40 °C span tested, the time-of-flight reading on a 300 mm stroke would shift by about 300 mm × 3 × 10⁻⁶ × 40 ≈ 0.036 mm. Ask the supplier how temperature is compensated and what the stated temperature coefficient is. [3]
Micro-Epsilon describes its induSENSOR DTA LVDT as a plunger moving freely inside the sensor housing and joined to the measured object by a thread, measuring without contact and therefore wear-free, for movements, positions, strokes and deflections in vehicles, machines and systems; resolution is limited by the controller's noise, the symmetric design gives zero-point stability, and the sensor runs from an external controller at 1–5 kHz excitation and 550 mV. [2]
A 2026 University of Antwerp study in Sensors describes the industrial LVDT as a movable ferromagnetic core sliding inside one primary and two secondary coils: with the primary excited by a high-frequency current, axial core movement induces a differential secondary voltage proportional to position. The authors note that commercial designs are optimised for robustness, range and cost, and for gravitational-wave instruments they built a variant with a moving primary coil, excited at 20 mA and 10 kHz in their simulations. Their sizing rule sets the primary coil height at no less than 2 × (S + Ms) for a ±S range plus a safety margin Ms, with a 5–10% margin for tightly constrained motion (for a ±5 mm range, "a margin of ±0.5 mm is generally adequate"); the optimised prototype gave a 2.8-fold increase in LVDT response over the initial design while keeping linearity. [4]
Editorial calculation: with that rule, a ±5 mm range and ±0.5 mm margin need a moving primary coil at least 2 × (5 + 0.5) = 11 mm long in that design, so the coil assembly is longer than the range it measures; ask an LVDT supplier for body length against the stroke you need. [4]
Give the supplier the measuring range or stroke, required linearity, repeatability and resolution, update rate, output or interface, supply voltage, mounting (rod in cylinder, profile, rod-and-cylinder, plunger), magnet or plunger connection, temperature, pressure, shock and vibration, sealing, cable and connector, and quantity.
02
Set accuracy, output and environmental ratings
The Temposonics ER SSI lists resolution of 20, 50 or 100 µm; measurement rates of 3.7 kHz at 300 mm stroke falling to 1.2 kHz at 2,000 mm; linearity ≤ ±0.02 % F.S. (minimum ±60 µm) and repeatability ≤ ±0.005 % F.S. (minimum ±20 µm); SSI output with 24 or 25-bit data at 70 kBd to 1 MBd depending on cable length; +24 VDC supply with 90 mA (typ.) consumption; −40 to +75 °C; 90 % RH without condensation; IP67 for the electronics housing with correctly fitted connectors; 100 g shock and 5 g at 10–2,000 Hz vibration; EN 61000-6-2/-3 EMC; magnet speed up to 5 m/s; and an M12 8-pin connector. [1]
Micro-Epsilon lists DTA models of ±1, ±3, ±5, ±10, ±15 and ±25 mm with independent linearity from ≤ ±0.4 % to ≤ ±0.15 % FSO depending on model and grade (for example ≤ ±3 µm on ±1 mm), ≤ ±0.05 % FSO with a linearized controller, zero drift ≤ 70 ppm FSO/K, sensitivity of 29–127 mV/mm/V, operation from −20 to +90 °C (to −40 °C with the cable at rest and +105 °C for up to 500 h), 5 bar pressure resistance at the front, 40 g/100 g shock and 20 g vibration ratings, IP67, a stainless steel housing and sensor weights of about 80–145 g. [2]
Editorial calculation: ±0.02 % of a 1,500 mm stroke is ±0.3 mm, and ±0.005 % is ±75 µm; ±0.15 % FSO of ±1 mm (2 mm span) is ±3 µm. [1][2]
03
One linked maker of pen-type LVDTs, and what to ask any supplier
Shenzhen Xinwei Technology is the company shown below; its page lists spring-return pen-type LVDT displacement sensors.
Ask any supplier for principle, stroke range, linearity and repeatability with their definitions, resolution, update rate, output and interface, supply and consumption, temperature drift, operating temperature, pressure rating for in-cylinder use, shock and vibration tests, IP rating and its conditions, materials, connector, and EMC compliance.
04
Waveguide, coil and damper, magnet, windings, plunger, electronics and housing
Rows marked magnetostrictive or LVDT apply to that principle only; the electronics and housing rows apply to both.
3 companies list this product among what they make. Company figures are quoted from each
company's own website; every card states where the relationship came from.
Shenzhen Xinwei Technology Development Co., Ltd.
Manufacturing site to be confirmed for the order
Its website lists spring-return pen-type LVDT displacement sensors.
Explore company information and manufacturing capabilities, then discuss the scope of your project with a relevant supplier.
Share this page
Compiled and source-reviewed by the CNFX editorial team.
Each manufacturer above links to the page on that company's own website where the product is listed, with the date we checked it. How we source and review
· Page last updated 13 October 2026
Buyer questions
How does a magnetostrictive position sensor work?
Temposonics times a torsional strain pulse released where a moving magnet sits on a waveguide; the time of flight gives position. [1]
What is an LVDT?
Micro-Epsilon describes a plunger moving without contact inside transformer windings, read by an external controller. [2]
Does IP67 cover the whole sensor?
Temposonics notes IP67 applies to the electronics housing with connectors fitted; check the conditions for any model. [1]
What limits the accuracy of a magnetostrictive position sensor?
Zhang et al. (Sensors 2011) identify electromagnetic interference in the time measurement; a differential two-waveguide design improved a 300 mm sensor from ±0.2 mm to ±0.1 mm. [3]
How is the coil of an LVDT sized to its range?
In the University of Antwerp moving-primary design, the primary coil is at least 2 × (range + safety margin) long, for example 11 mm for ±5 mm with a ±0.5 mm margin (Editorial calculation). [4]
Sources and what still needs a direct check
Sources checked 2026-10-11. Temposonics (MTS Sensors) makes magnetostrictive position sensors; Micro-Epsilon makes LVDT sensors. The Shanghai Jiao Tong University paper in Sensors (2011, open access in PMC) is independent research on magnetostrictive waveguide accuracy and temperature drift, and the University of Antwerp paper in Sensors (2026, open access in PMC) is independent research on LVDT coil design.